Hierarchical supervisor-agent
Permanent sensor noise evaluation
Duration: Permanent
Recovery mechanism: Hierarchical supervisor-agent
Experiment definition
The experiment evaluates Hierarchical supervisor-agent under a permanent sensor noise injection. Fault onset is randomized between environment steps 40 and 60.
Expected evaluation record
| Metric | Recorded value |
|---|---|
| Degradation-area | 27.57 ± 5.48 (corrected; mean ± 95% CI, n=72) |
| Safety-violation excess | 141.5 ± 28.6 (weighted, control-subtracted; mean ± 95% CI, n=72) |
| Fraction of time healthy | 0.563 ± 0.033 (mean ± 95% CI, n=72) |
| Relapse count | 0.42 ± 0.14 (mean ± 95% CI, n=72) |
| False-recovery rate | 0.258 ± 0.010 (mean ± 95% CI, n=72) |
| Intervention recall | 0.713 ± 0.013 (mean ± 95% CI, n=72) |
Values are means with 95% confidence intervals across every target × duration-fixed combination shown on this page (see graphs below), 8 evaluation seeds each, for each of 3 training seeds. See the Results page for the cross-mechanism comparison.
Experimental trajectory graphs
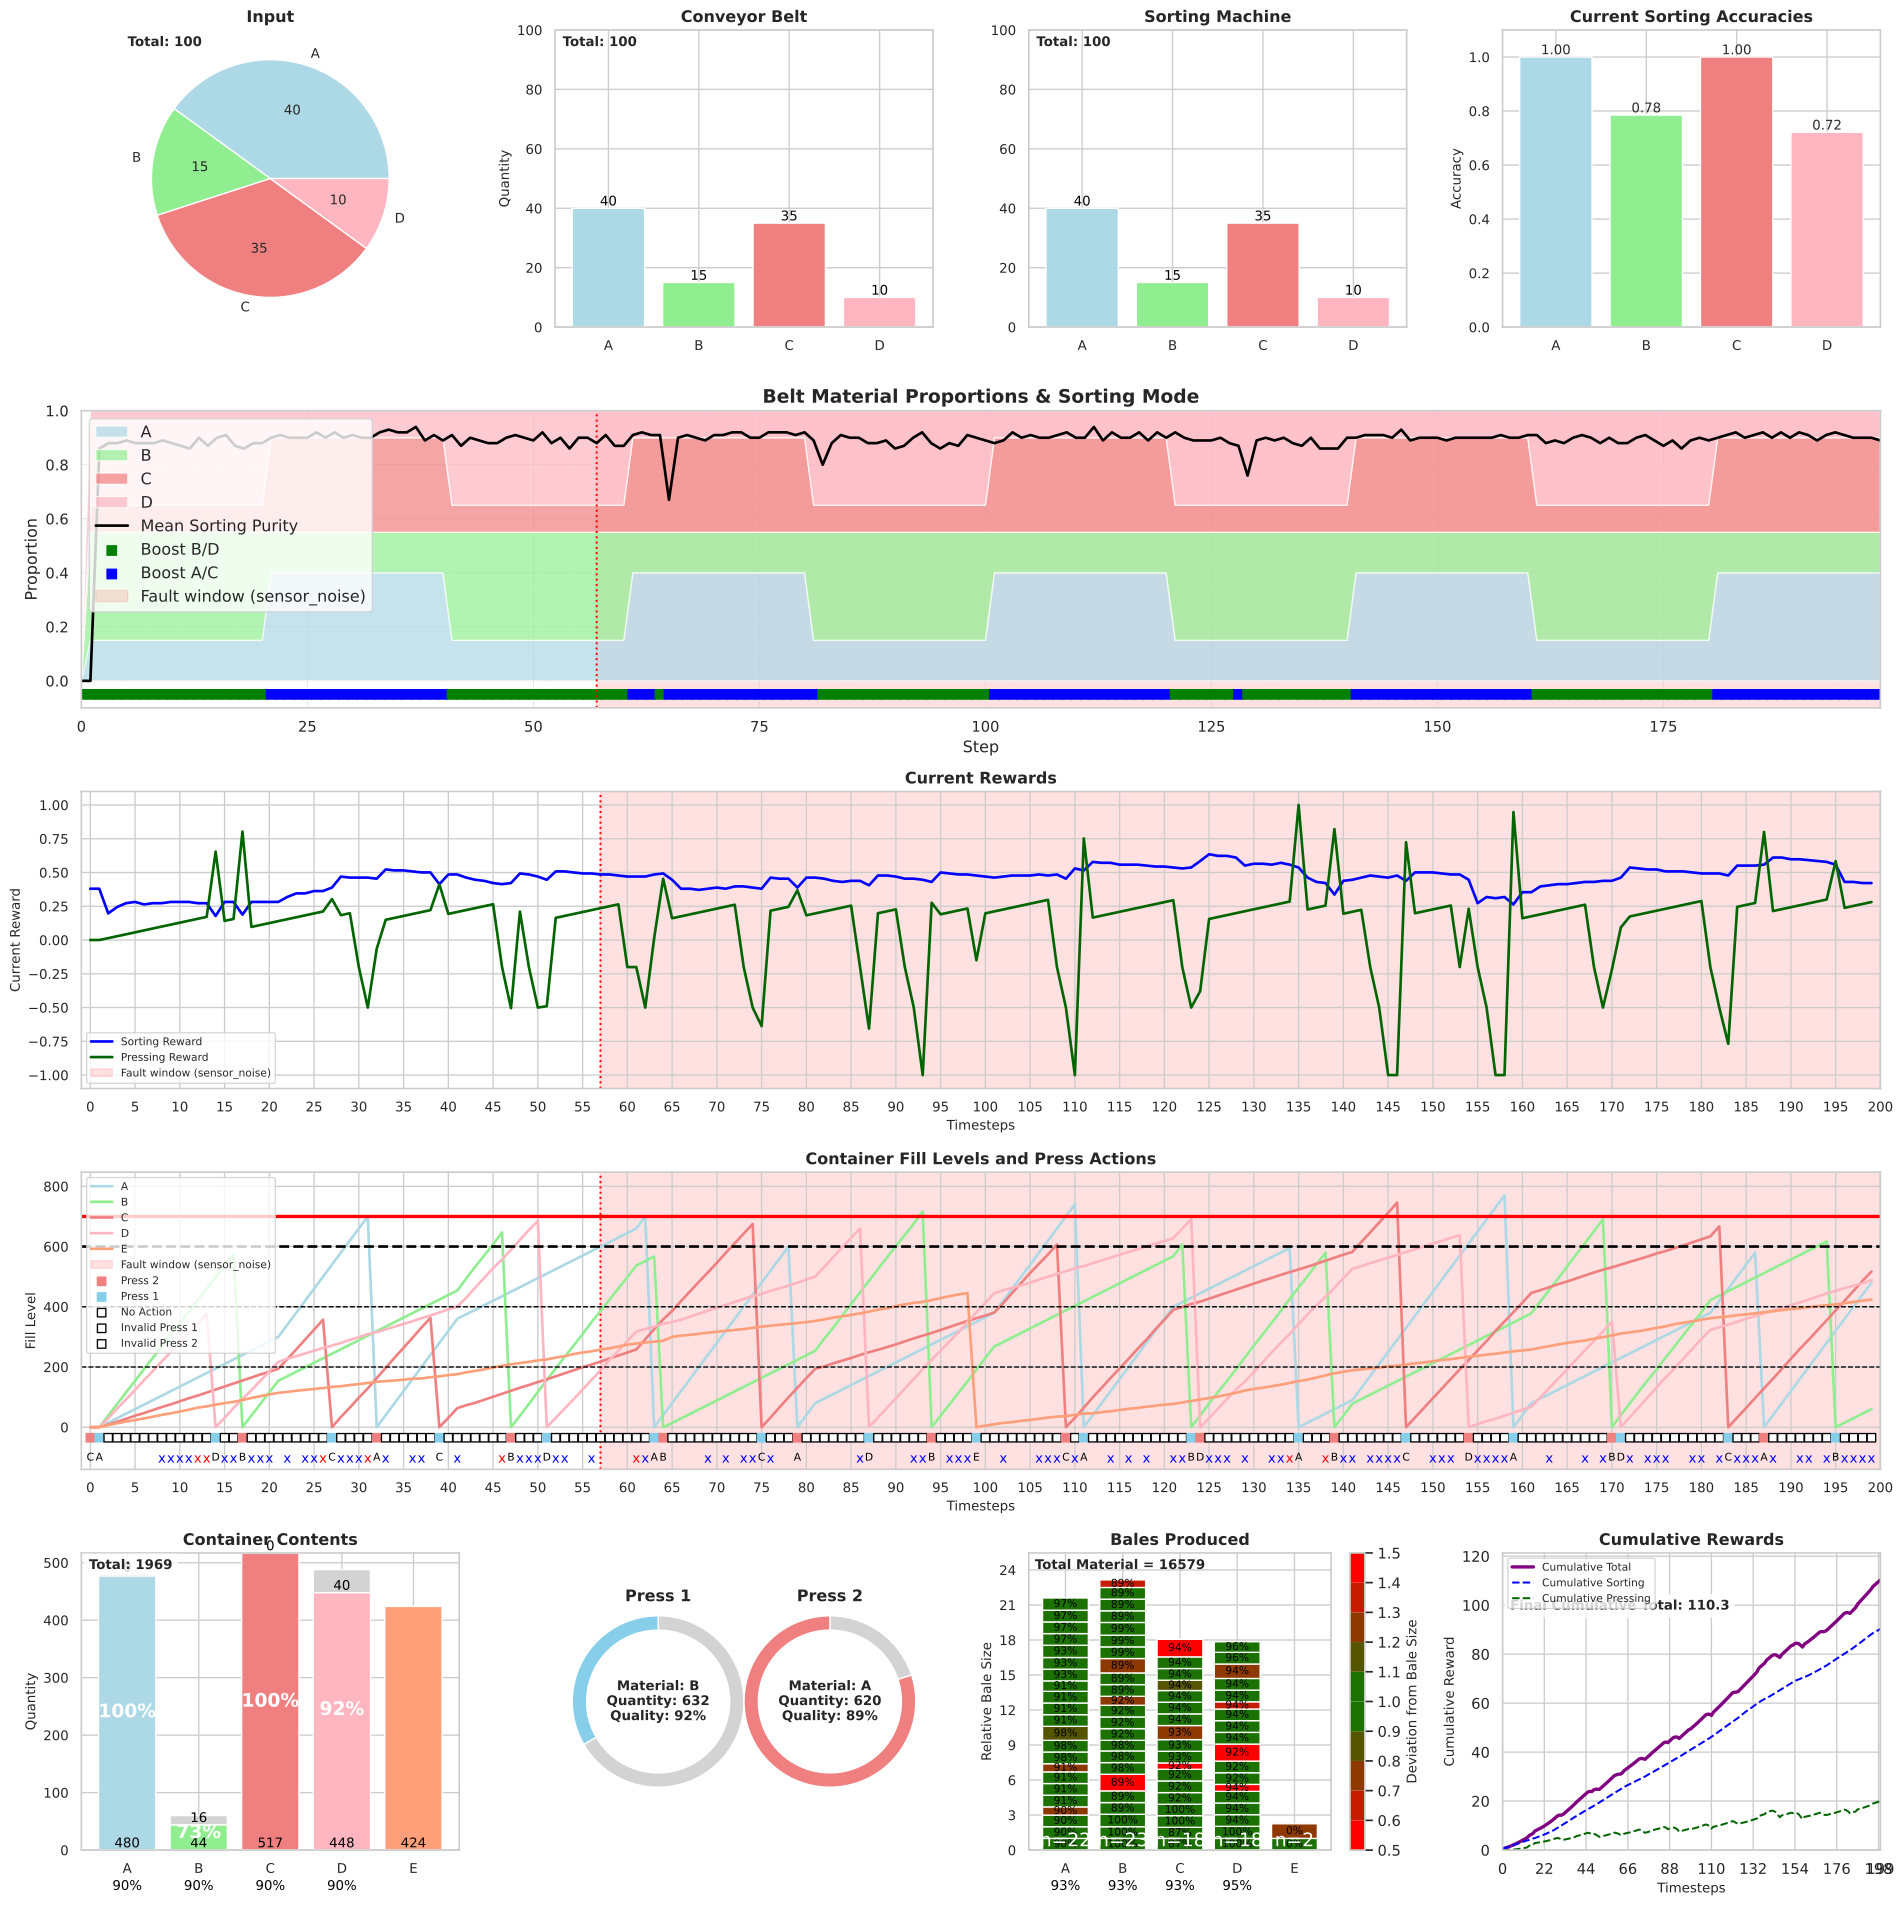
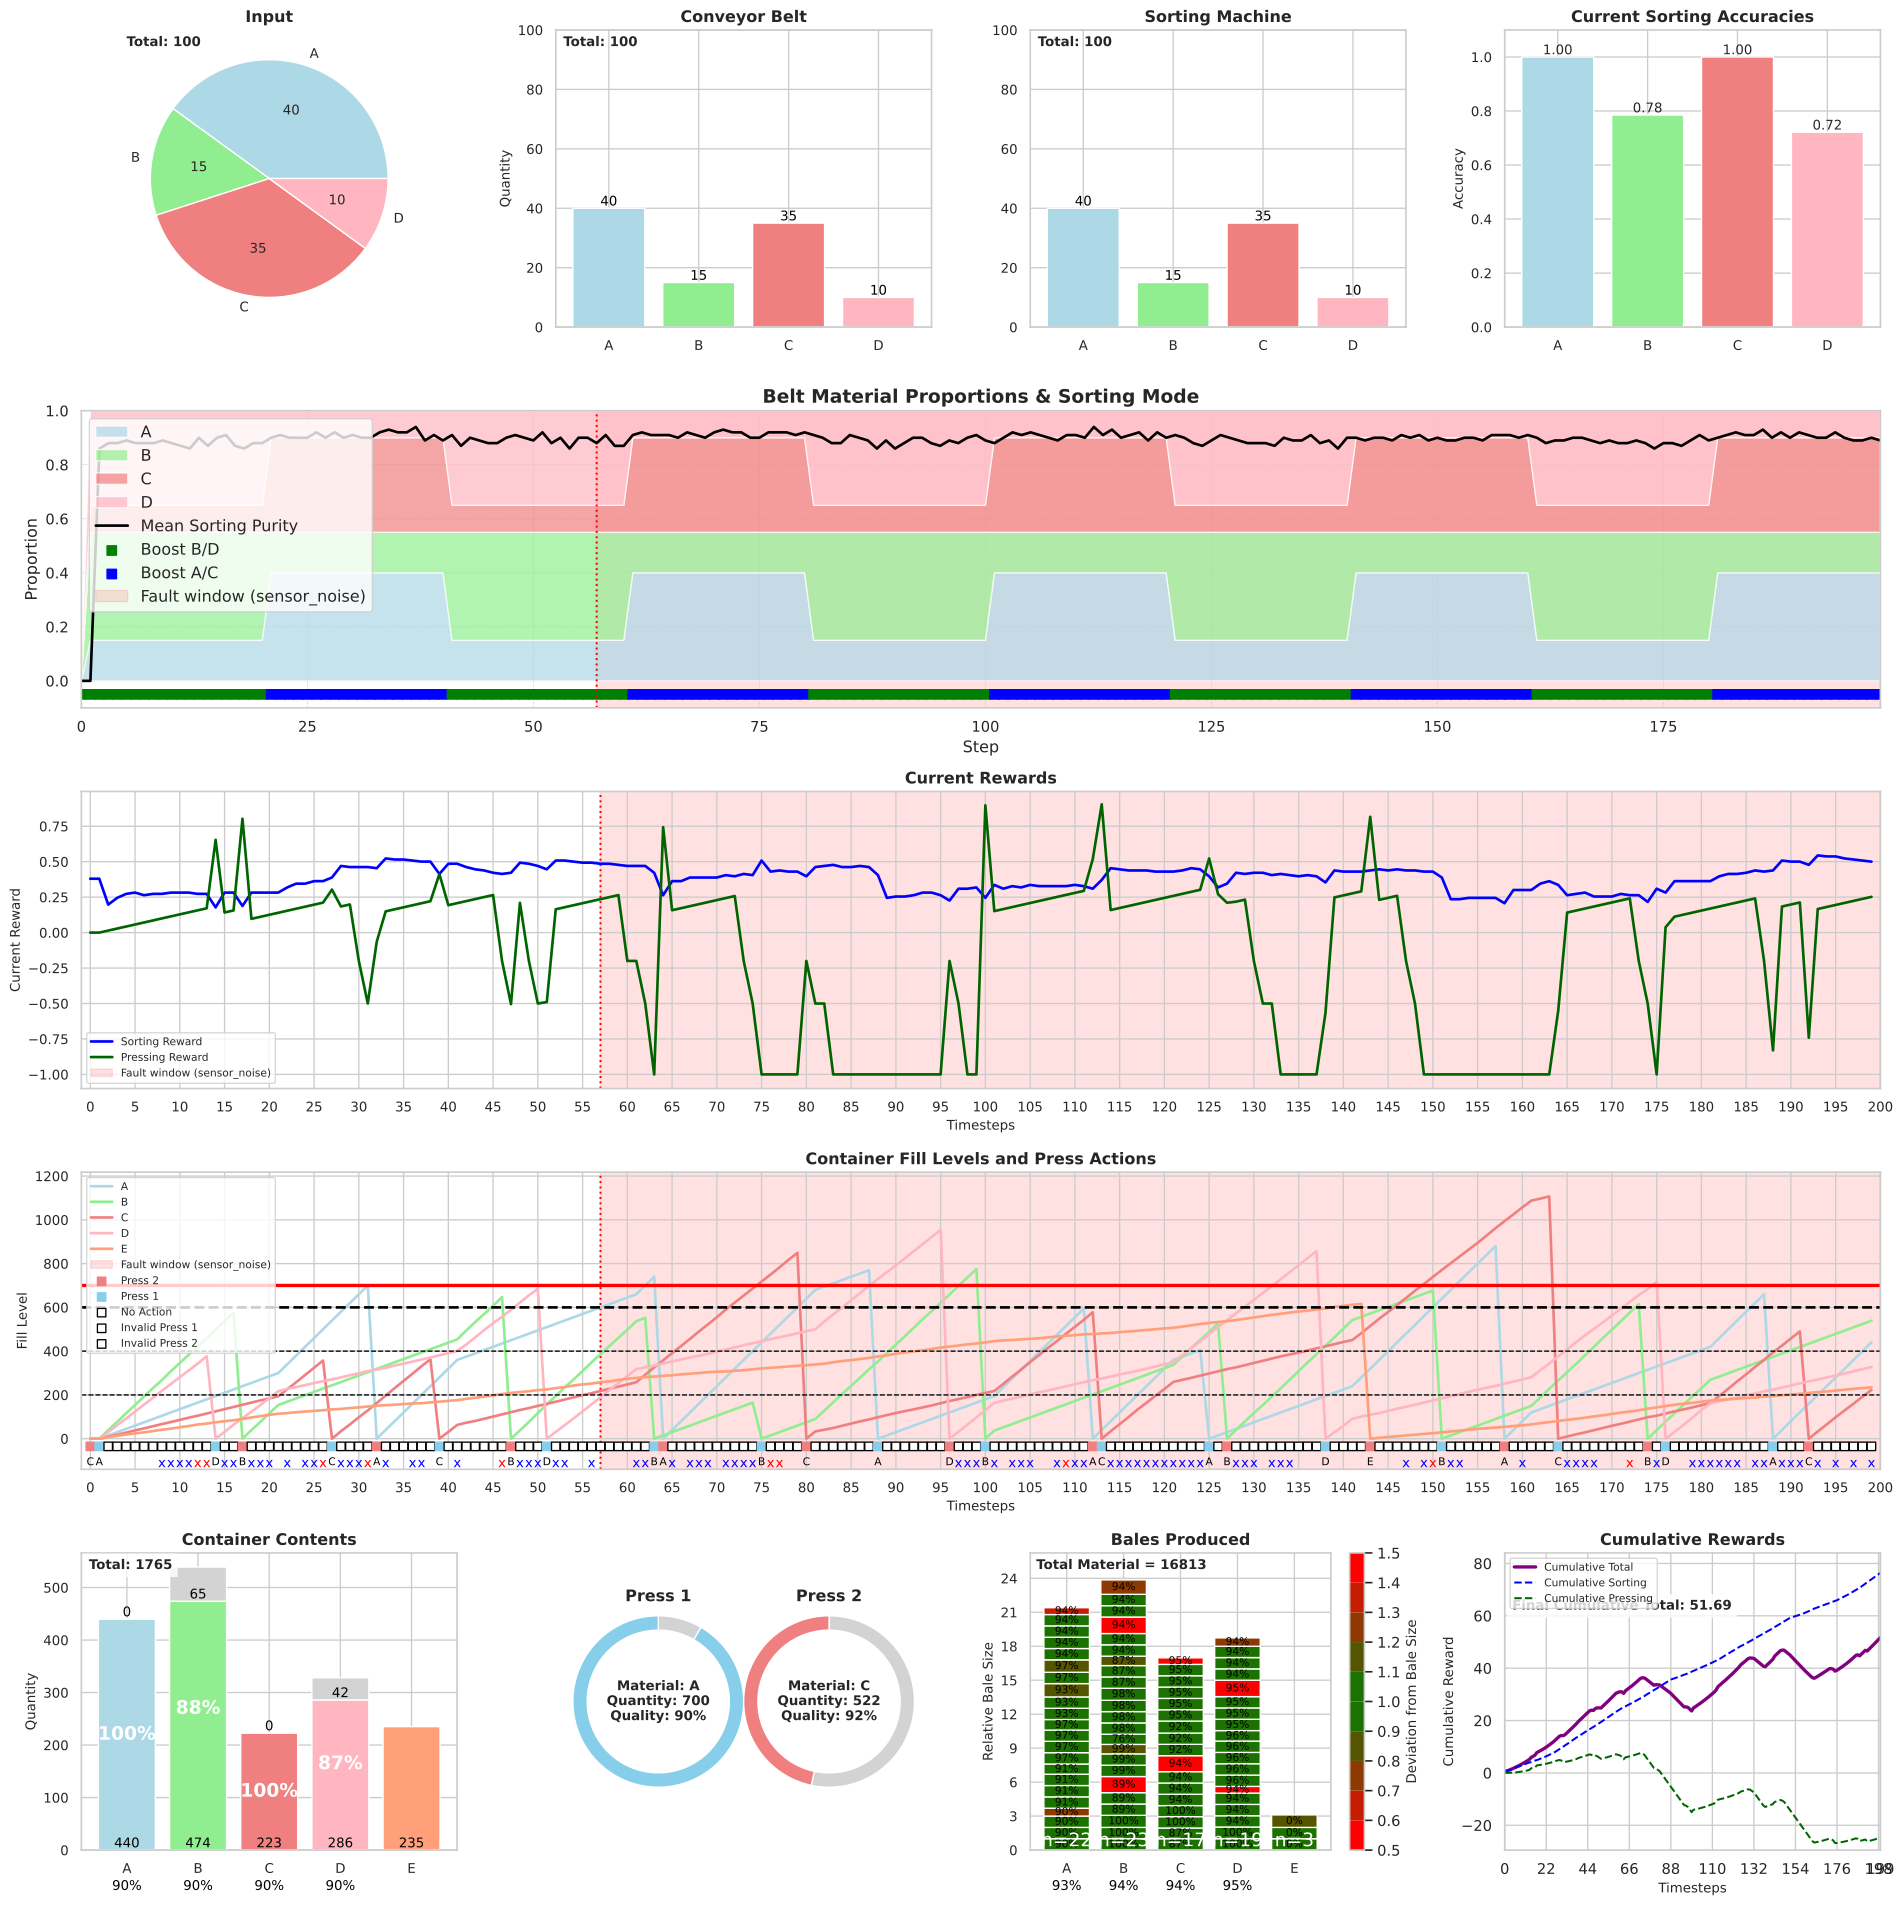
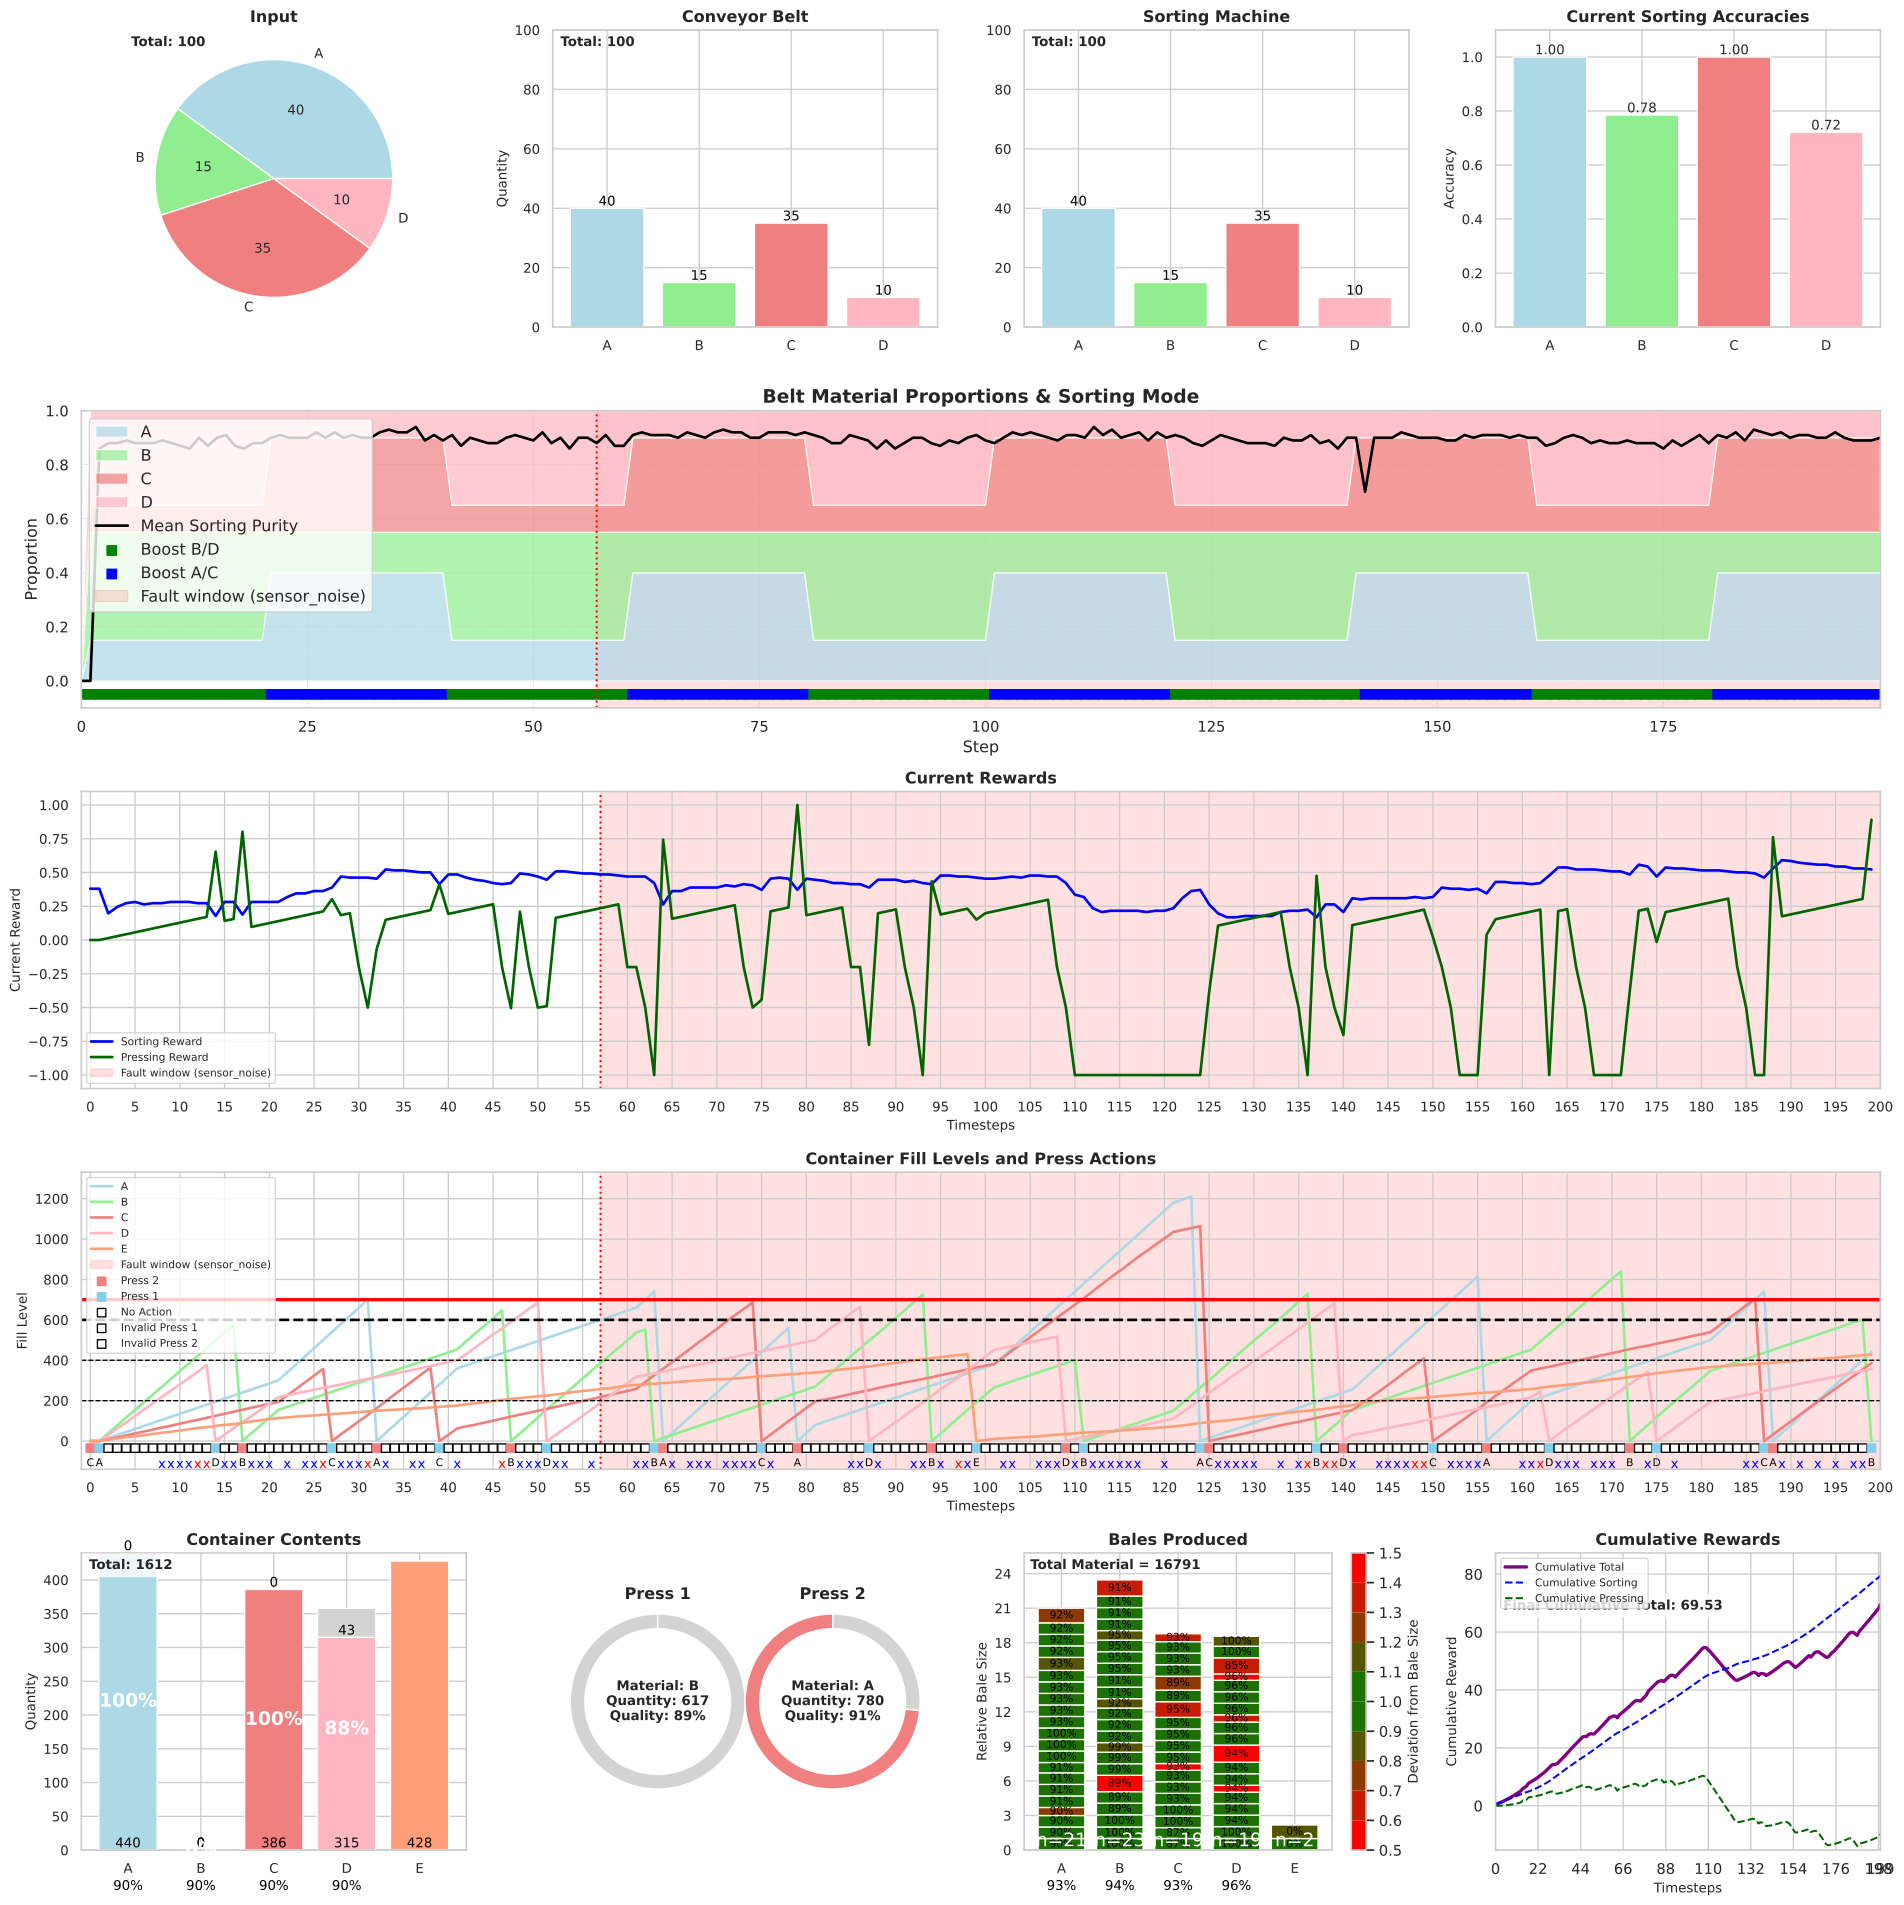
One representative run (evaluation seed 0 of 8, training seed 1 of 3) per target combination from the full sweep. See the Results page for the multi-seed aggregate comparison across mechanisms. The graphs for every seed are archived at doi:10.5281/zenodo.23304785 (files available from 10 November 2026).
Sorting Agent Target
Pressing Agent Target
Both Agents Target
Notes
This page is intentionally separated from the paper-facing results so that full-resolution plots, additional seeds, and diagnostic figures can be documented without overloading the publication.