Sensor noise adds zero-mean Gaussian noise (standard deviation 0.1 by default, on observations already scaled to a fixed range, then re-clipped to that range) directly to the local observation vectors of targeted agents. From injection onset (randomized between environment steps 40-60), the agent receives miscalibrated sensory feedback about belt composition, sorting purity, and container fill states while the physical environment continues to operate normally. This tests how effectively agents can maintain optimal control under distorted observation perception.
Experimental trajectory graphs
Permanent fault mode - Both Agents Target (std = 0.1)
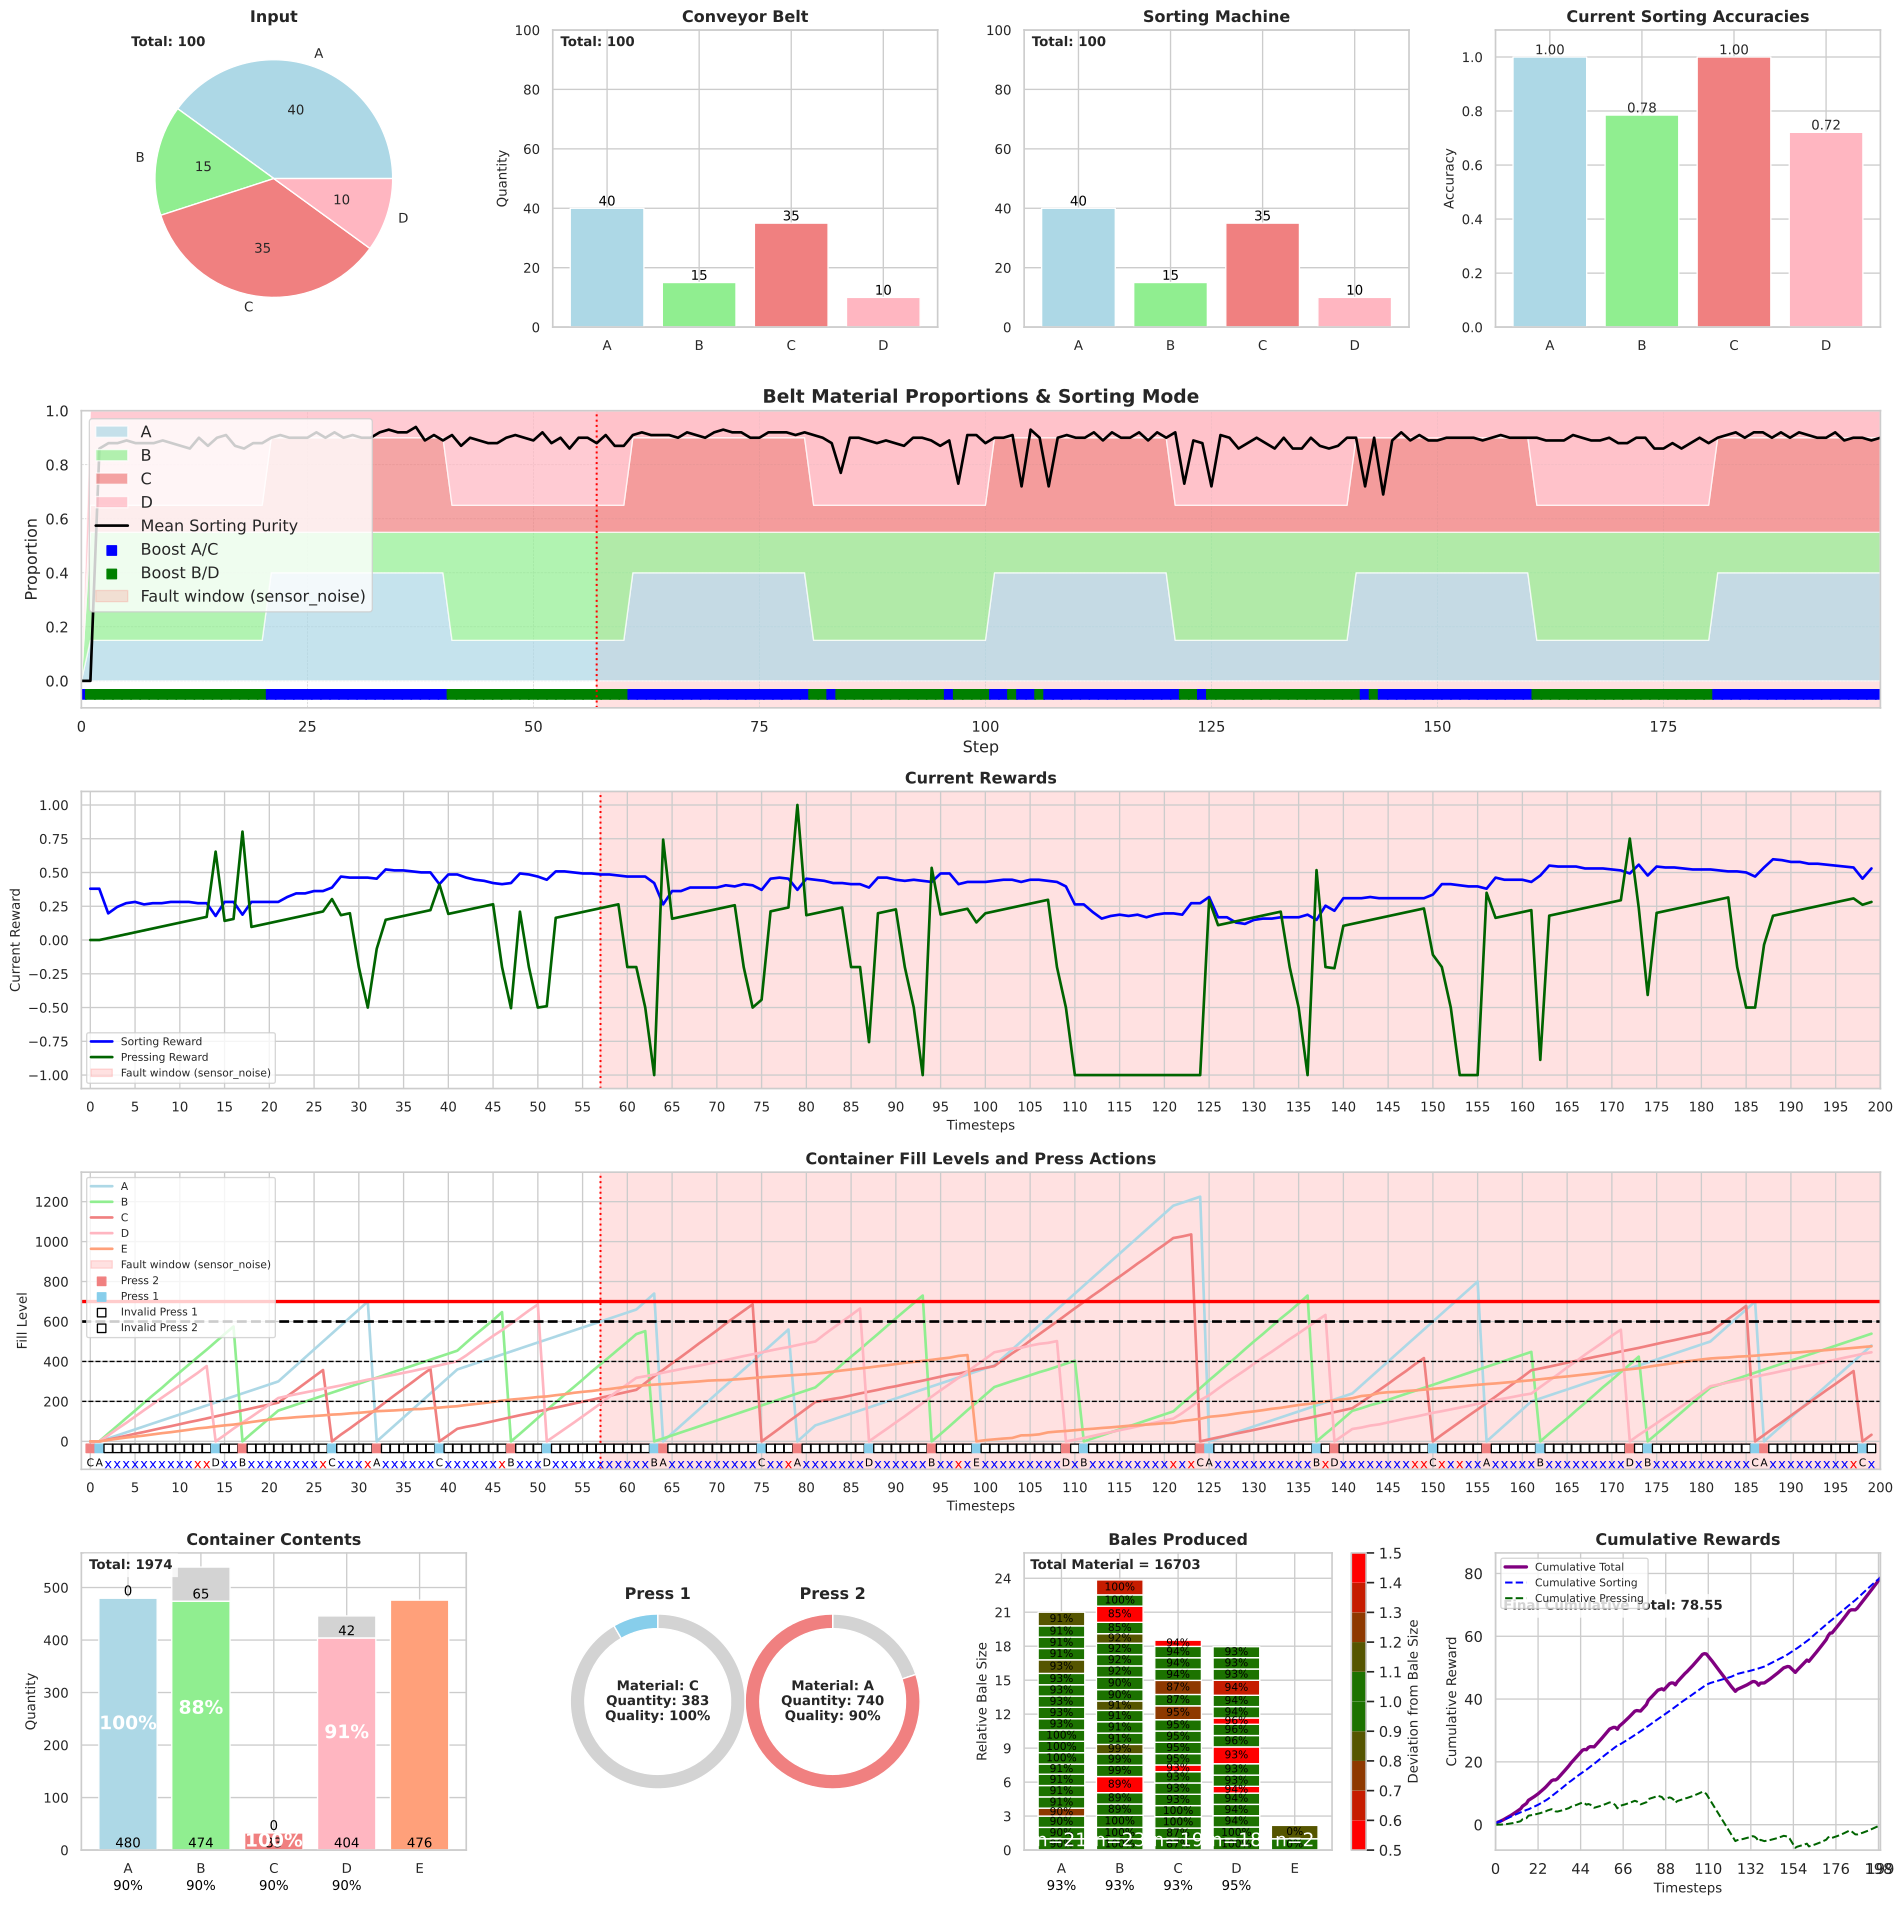
Permanent sensor noise fault trajectory (Both Agents Target, std=0.1) showing the active fault window (onset at step 57, persisting through step 200). Final cumulative reward: 78.55. No recovery mechanism, seed 0 of the 8-seed sweep.
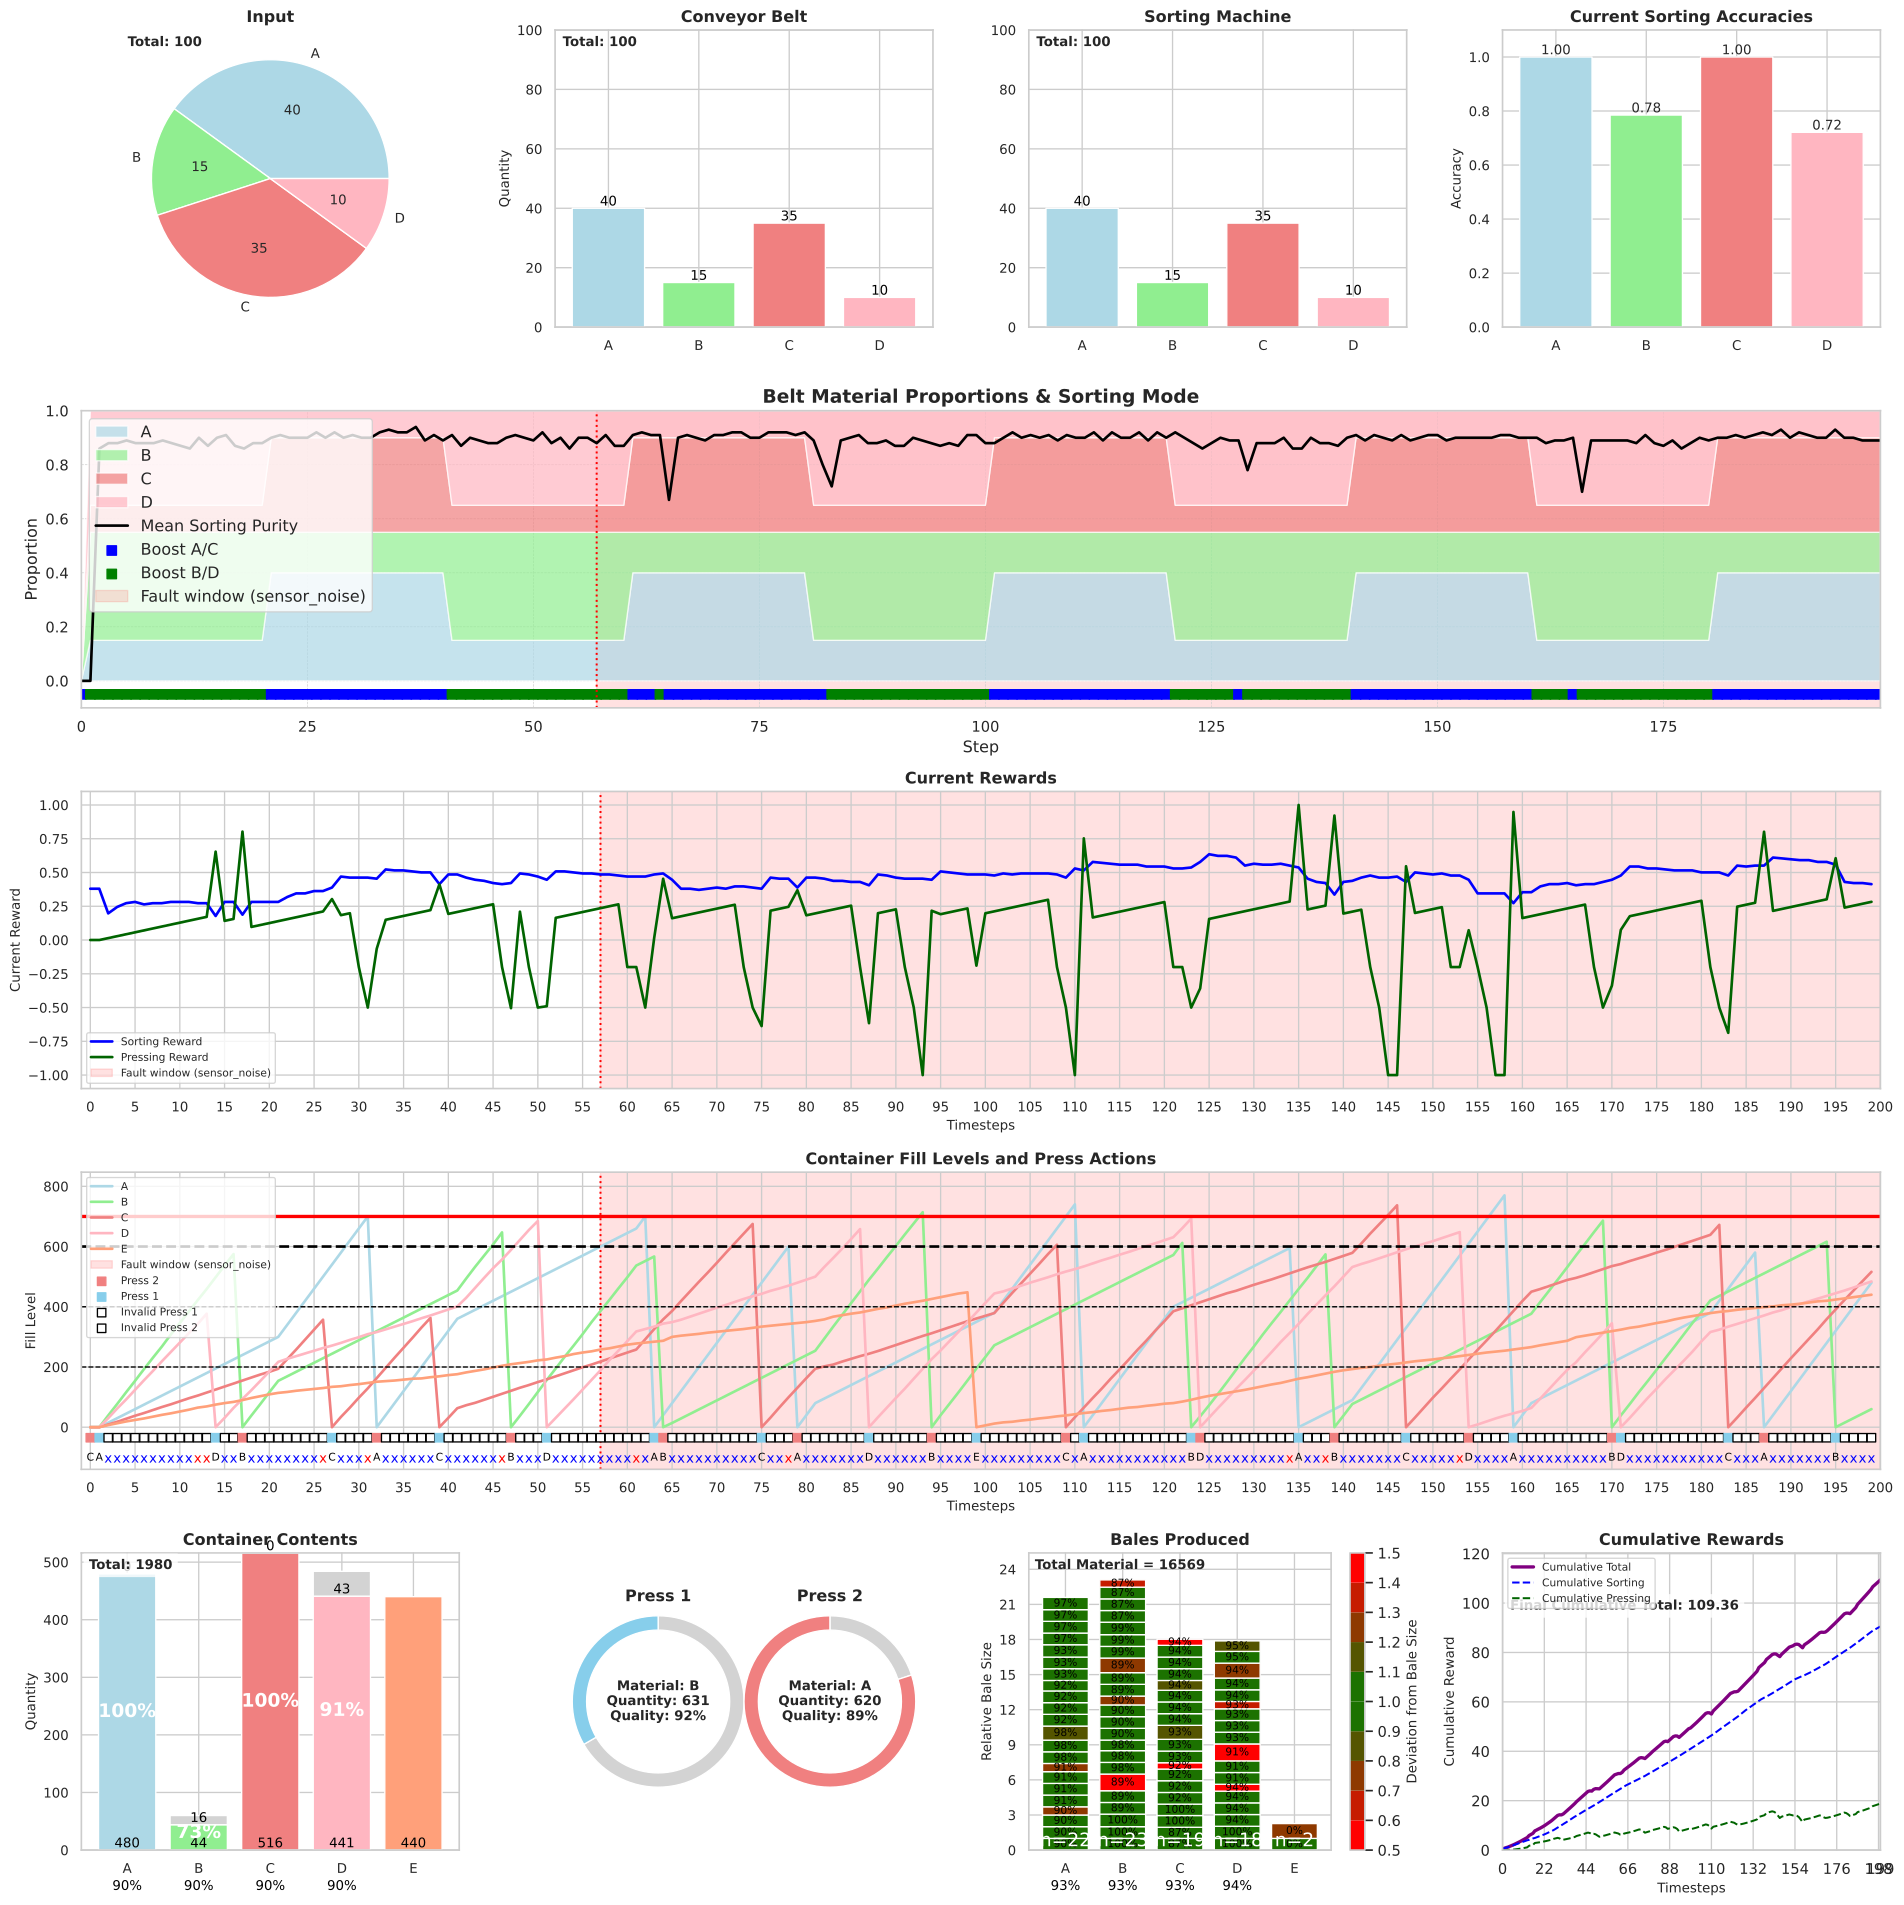
Permanent sensor noise fault trajectory targeting the sorting agent (std=0.1). Final cumulative reward: 109.36. No recovery mechanism, seed 0 of the 8-seed sweep.
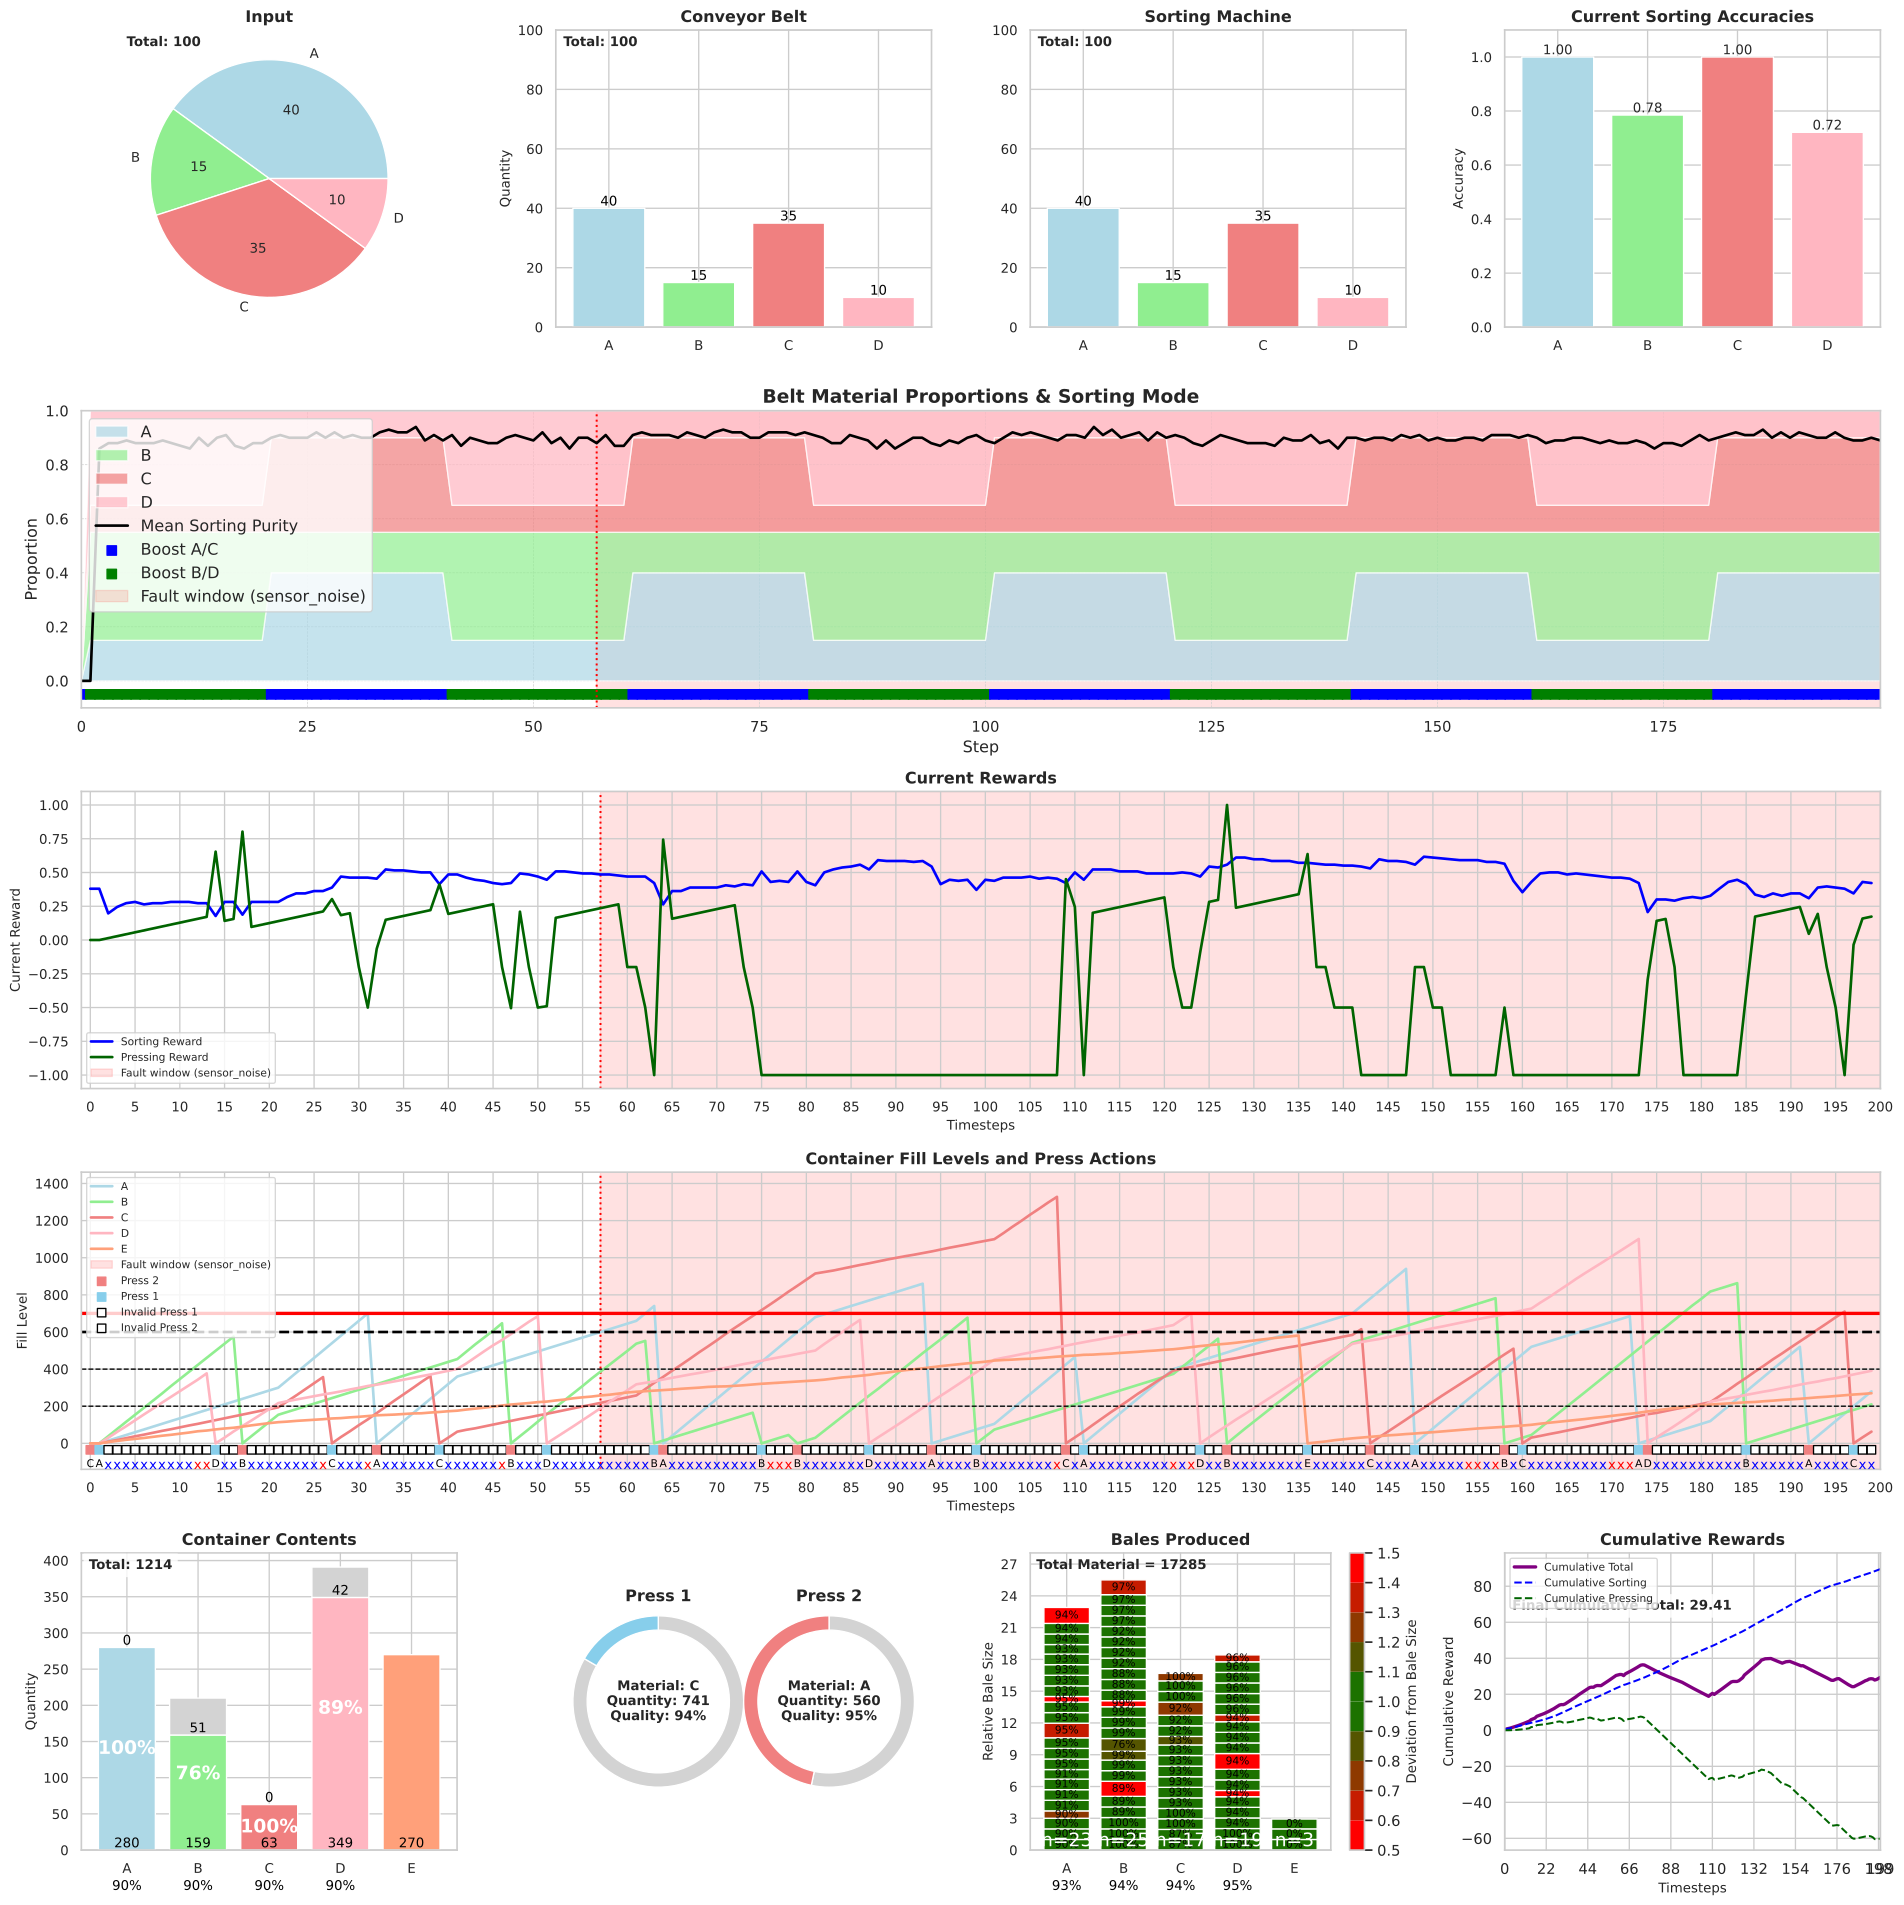
Permanent sensor noise fault trajectory targeting the pressing agent (std=0.1). Final cumulative reward: 29.41. No recovery mechanism, seed 0 of the 8-seed sweep.
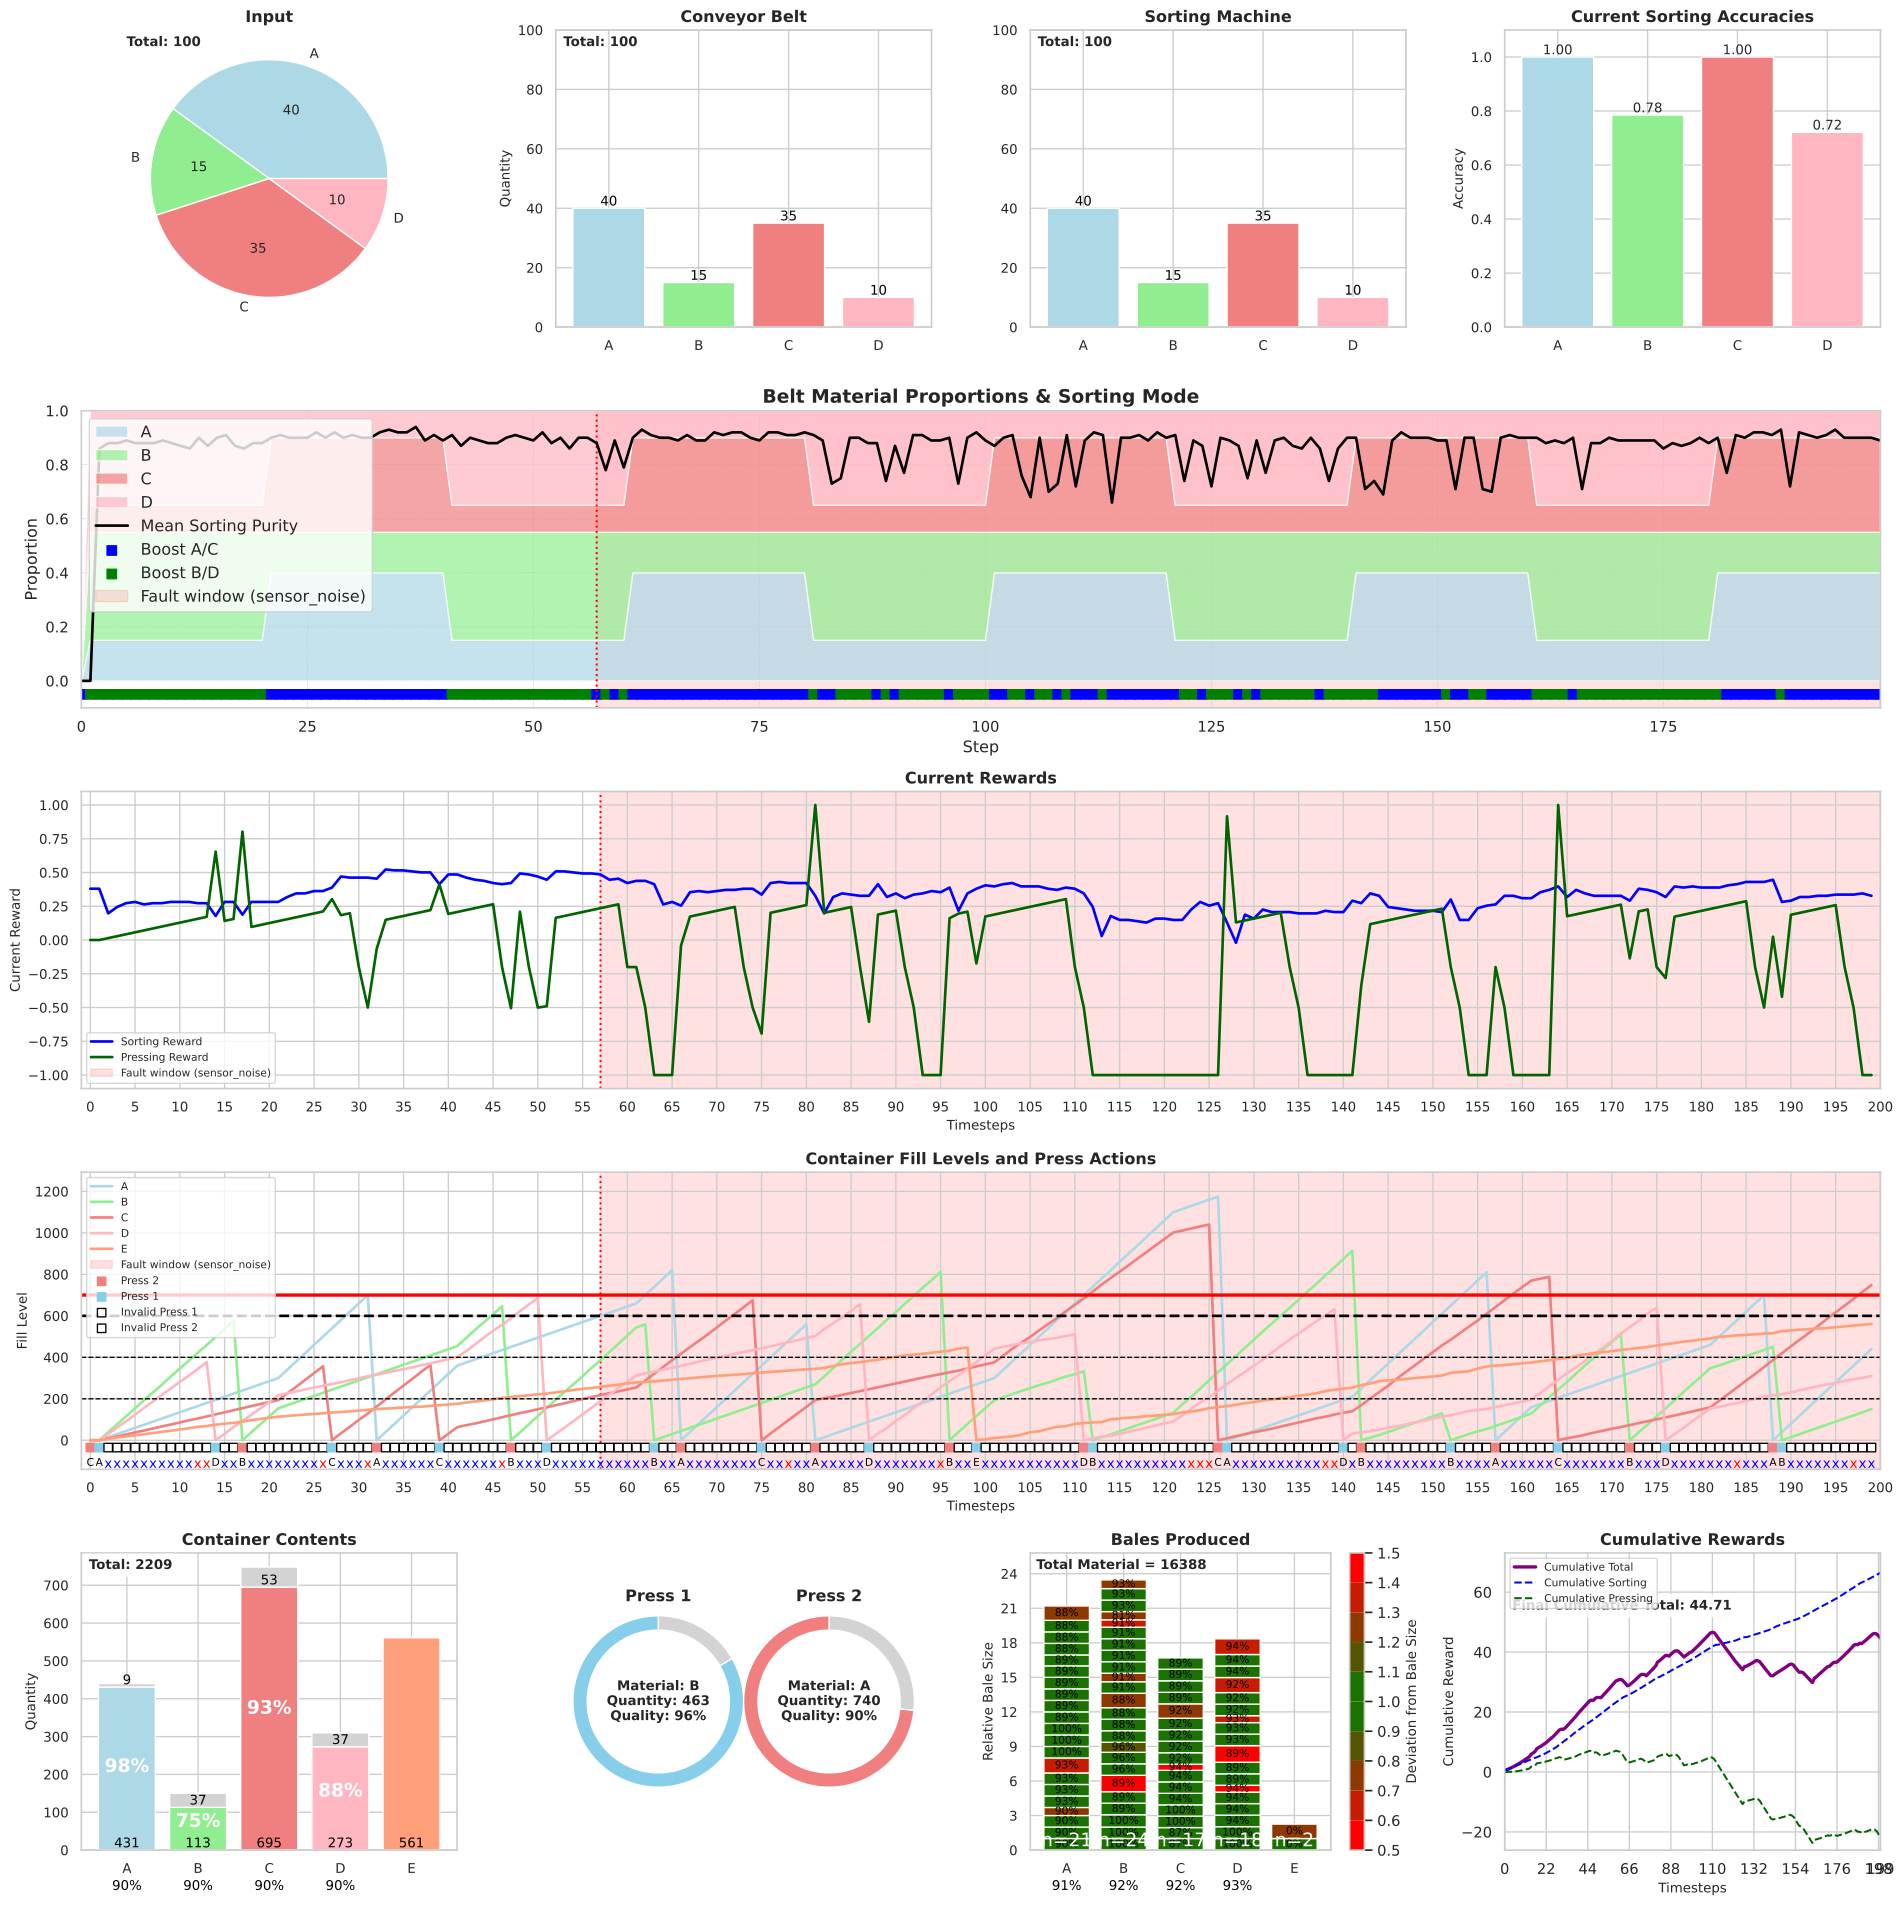
Permanent sensor noise fault trajectory under severe noise (Both Agents Target, std=0.2). Final cumulative reward: 44.71. No recovery mechanism; an extra run outside the main sweep (which uses std=0.1), with the same world and fault timing as seed 0.
Transient fault mode - Both Agents Target (std = 0.1, 20 steps, onset between steps 40-60)
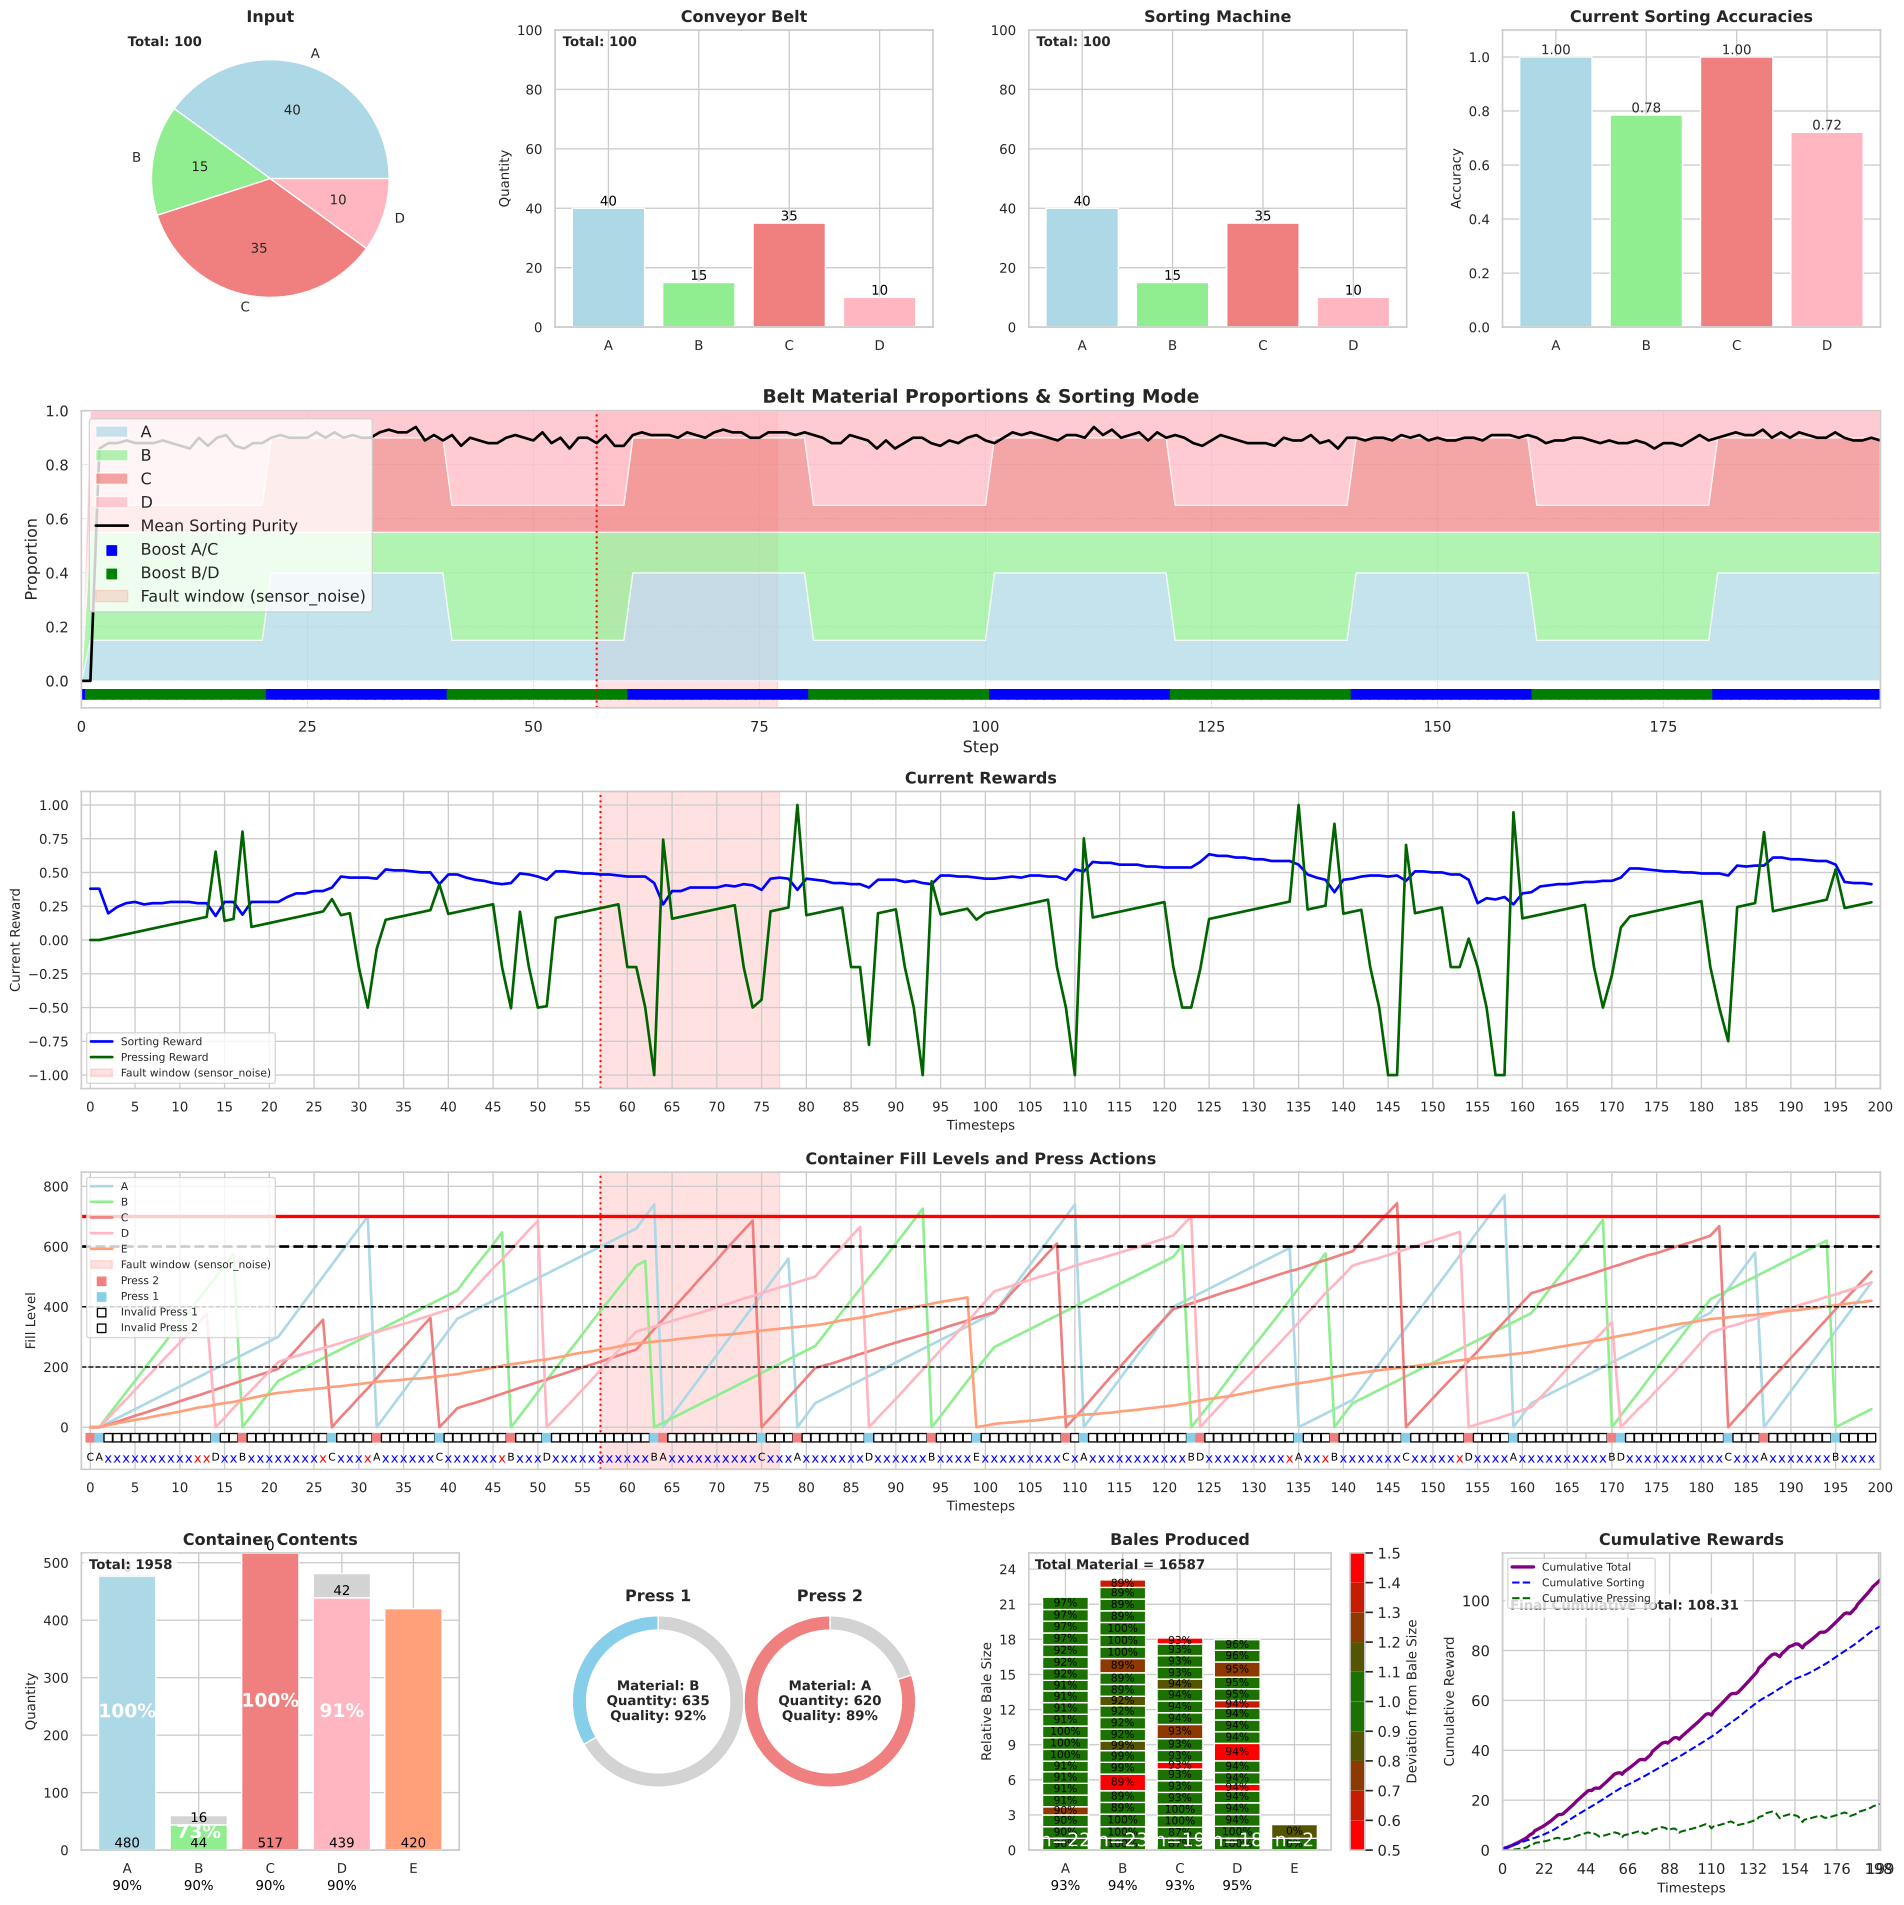
Transient sensor noise fault trajectory (Both Agents Target, std=0.1) active during steps 57-76. Final cumulative reward: 108.31. No recovery mechanism, seed 0 of the 8-seed sweep.
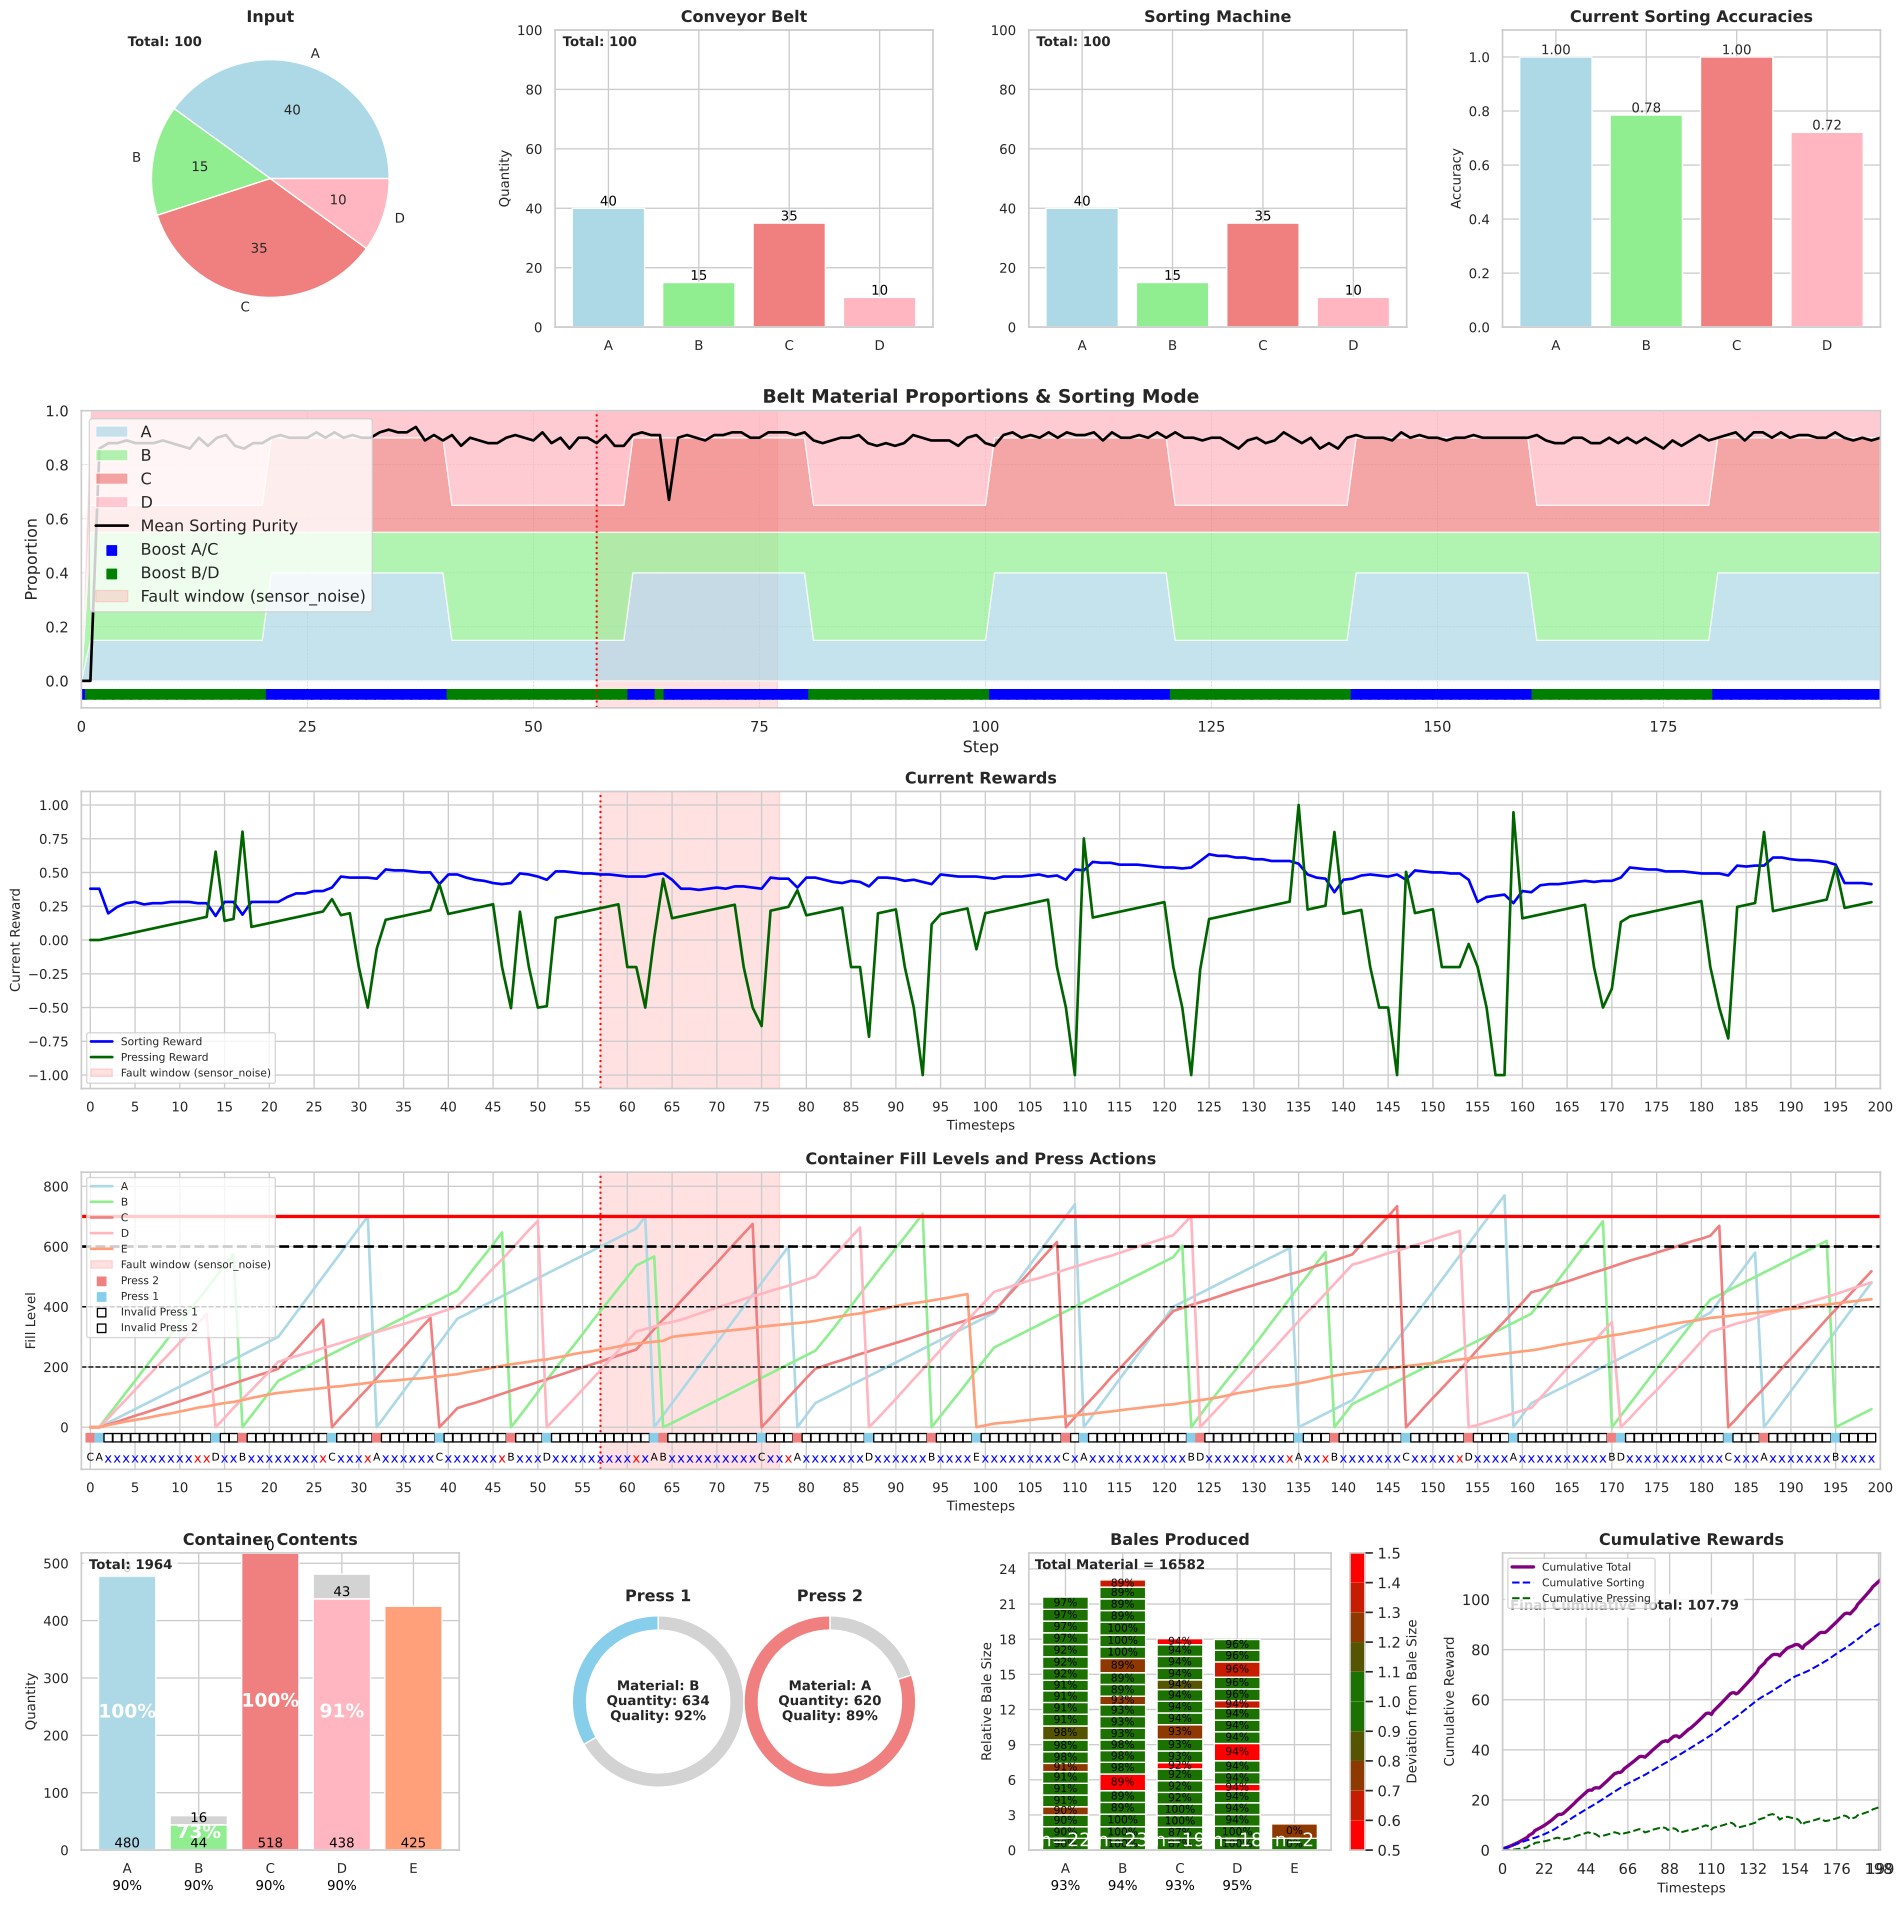
Transient sensor noise fault trajectory targeting the sorting agent (std=0.1, steps 57-76). Final cumulative reward: 107.79. No recovery mechanism, seed 0 of the 8-seed sweep.
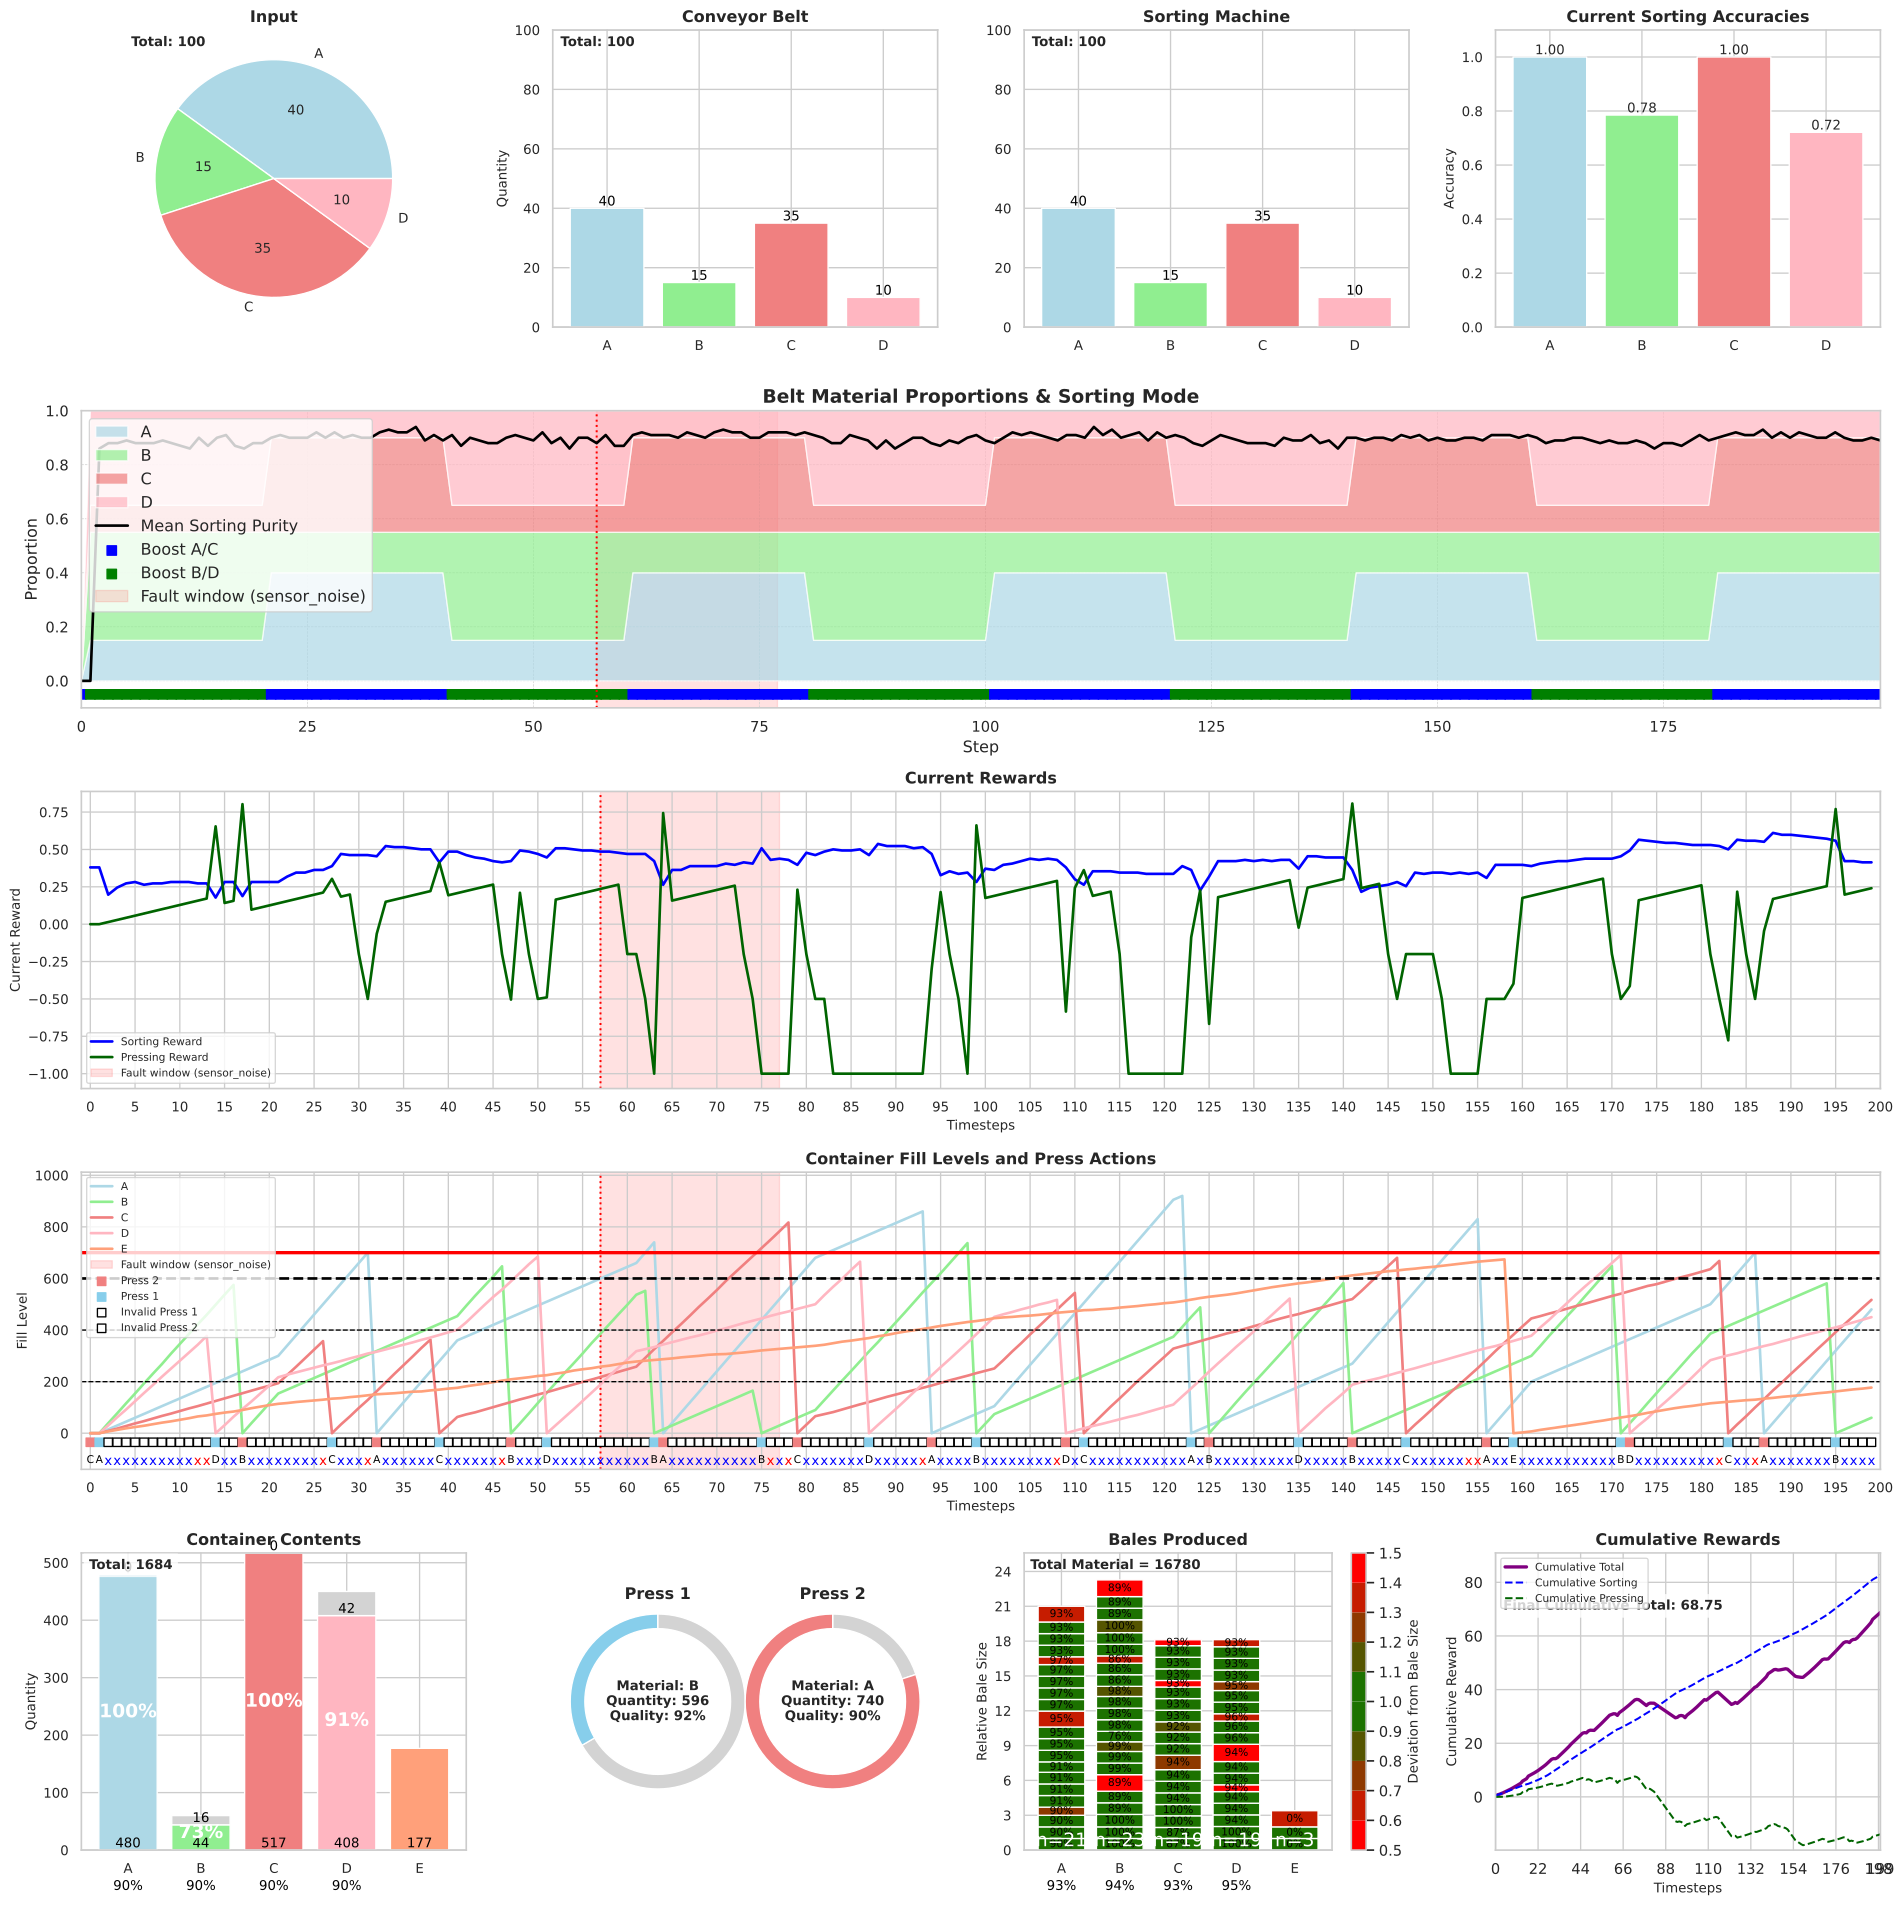
Transient sensor noise fault trajectory targeting the pressing agent (std=0.1, steps 57-76). Final cumulative reward: 68.75. No recovery mechanism, seed 0 of the 8-seed sweep.
Transient fault mode - Both Agents Target (High Noise, std = 0.2, 20 steps, onset between steps 40-60)
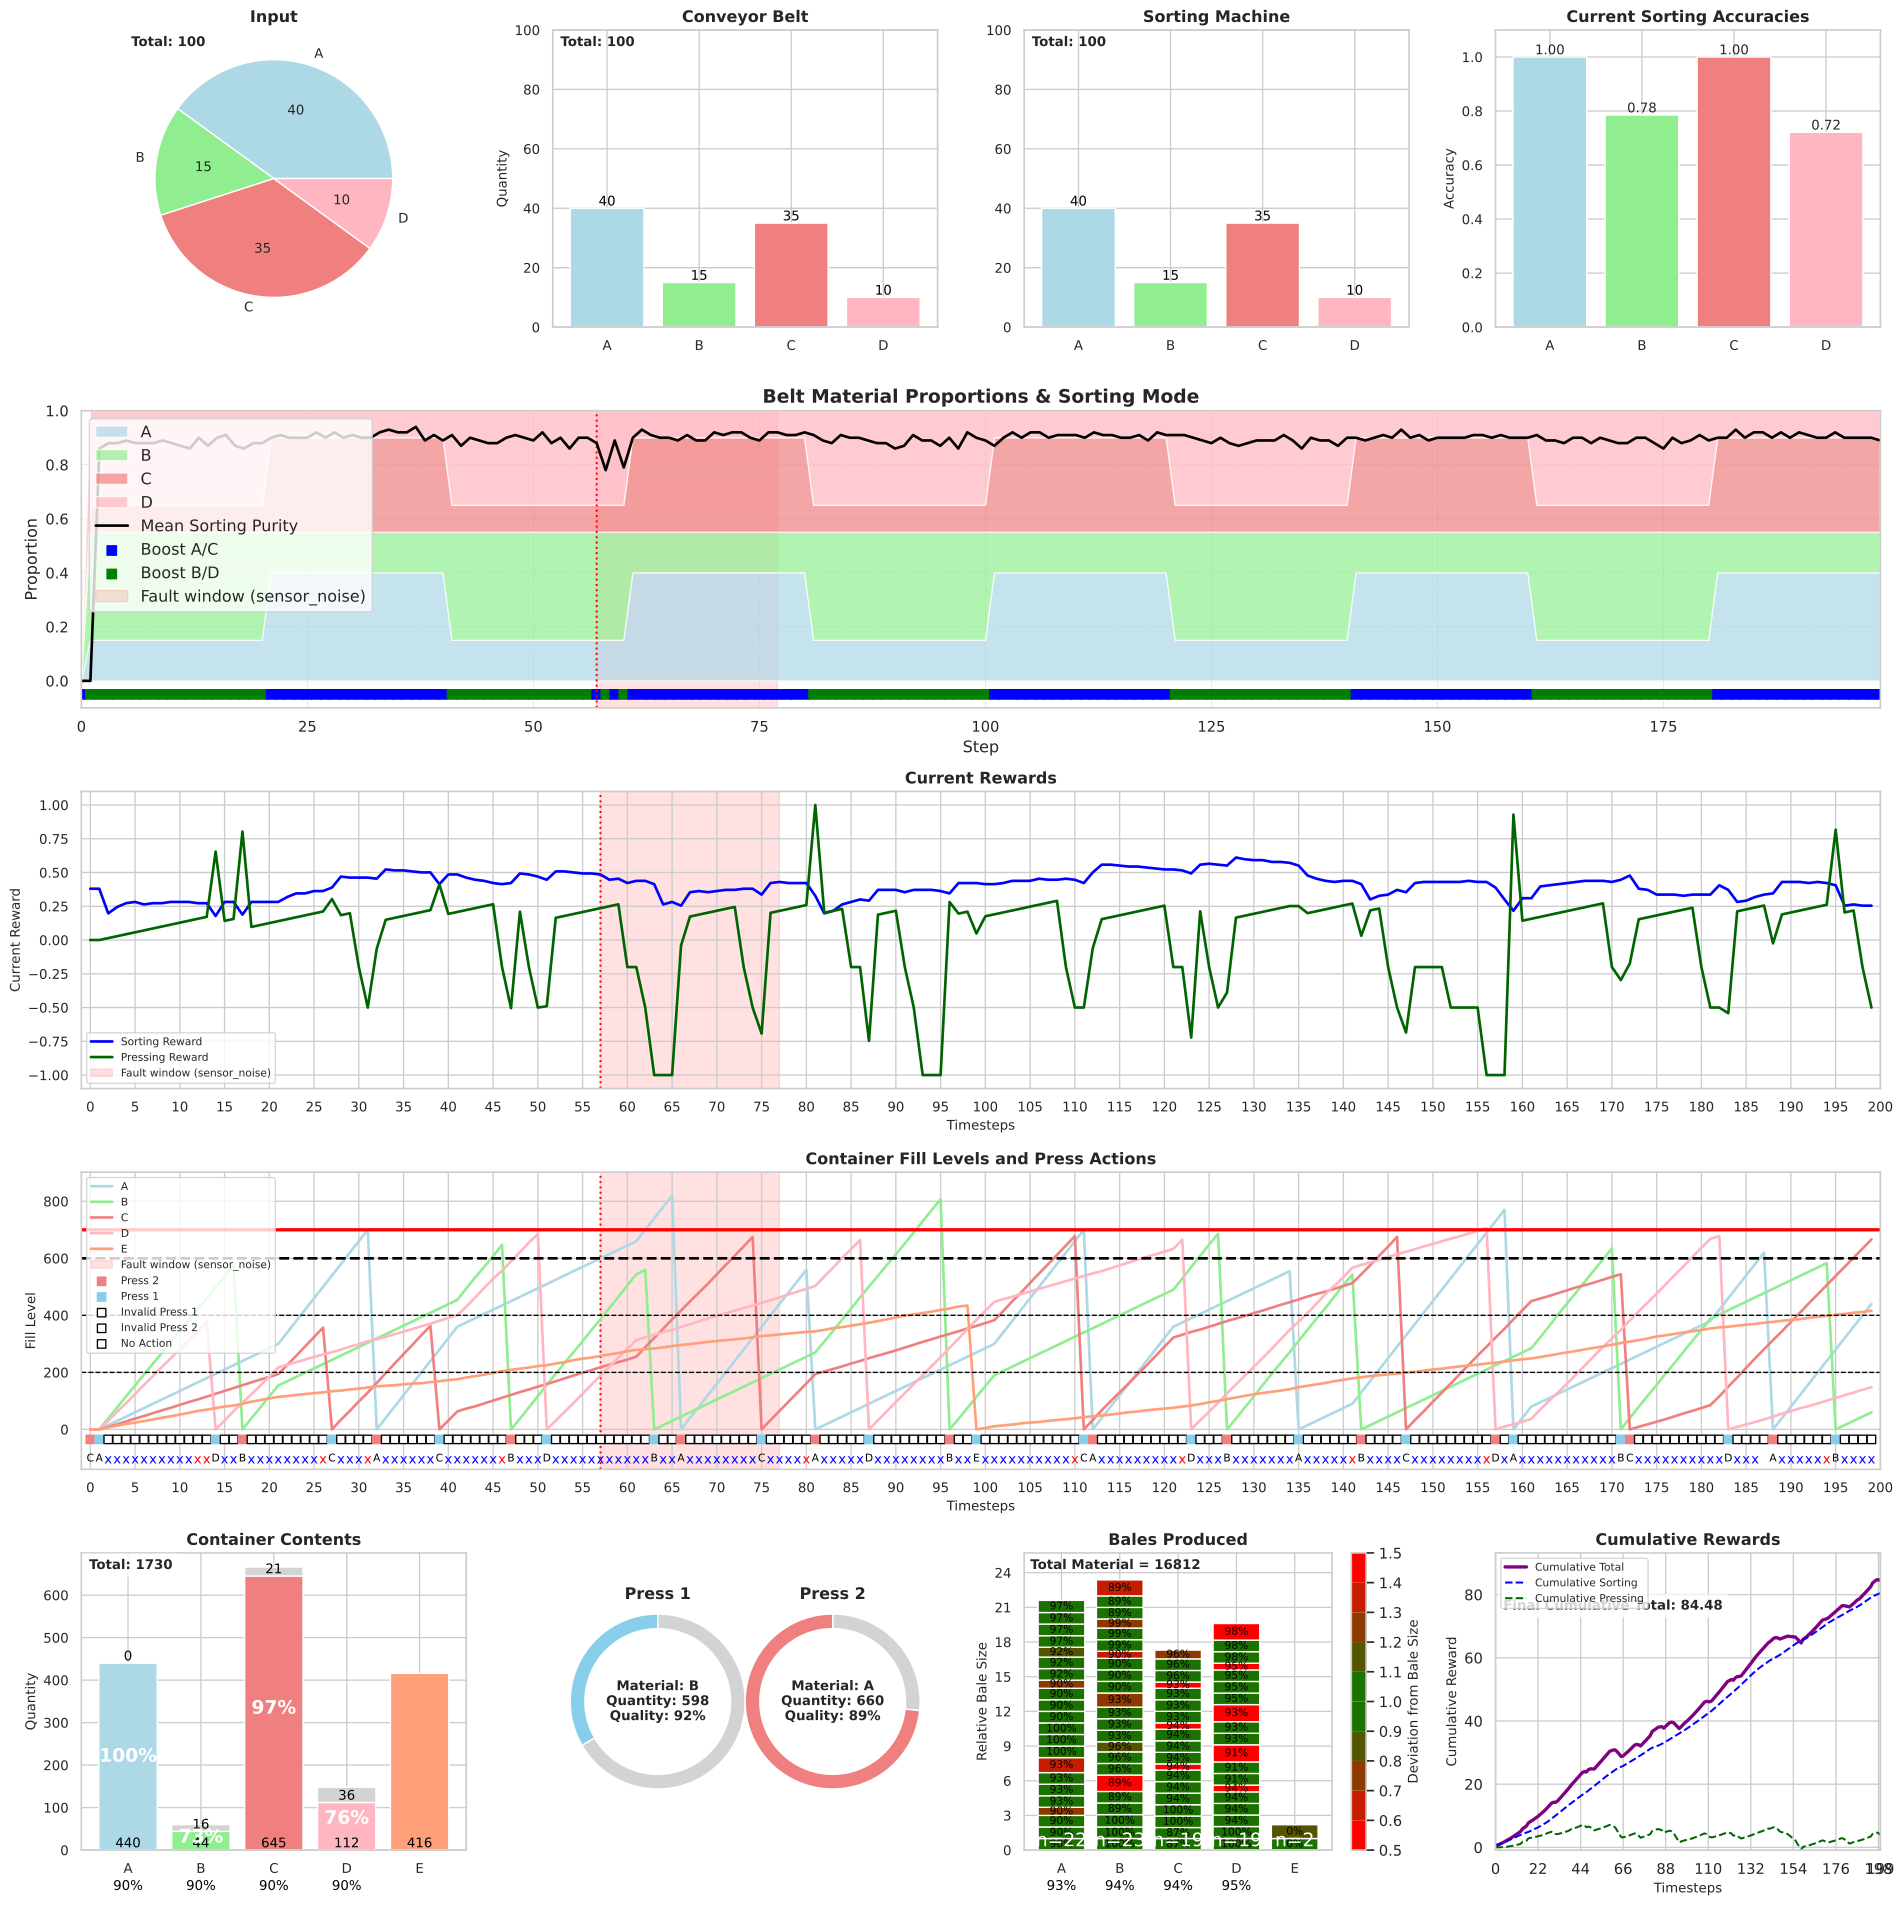
Transient sensor noise fault trajectory under severe noise (Both Agents Target, std=0.2, steps 57-76). Final cumulative reward: 84.48. No recovery mechanism; an extra run outside the main sweep (which uses std=0.1), with the same world and fault timing as seed 0.
Duration modes
Permanent: the fault persists until the end of the episode.